Wall-E robot.
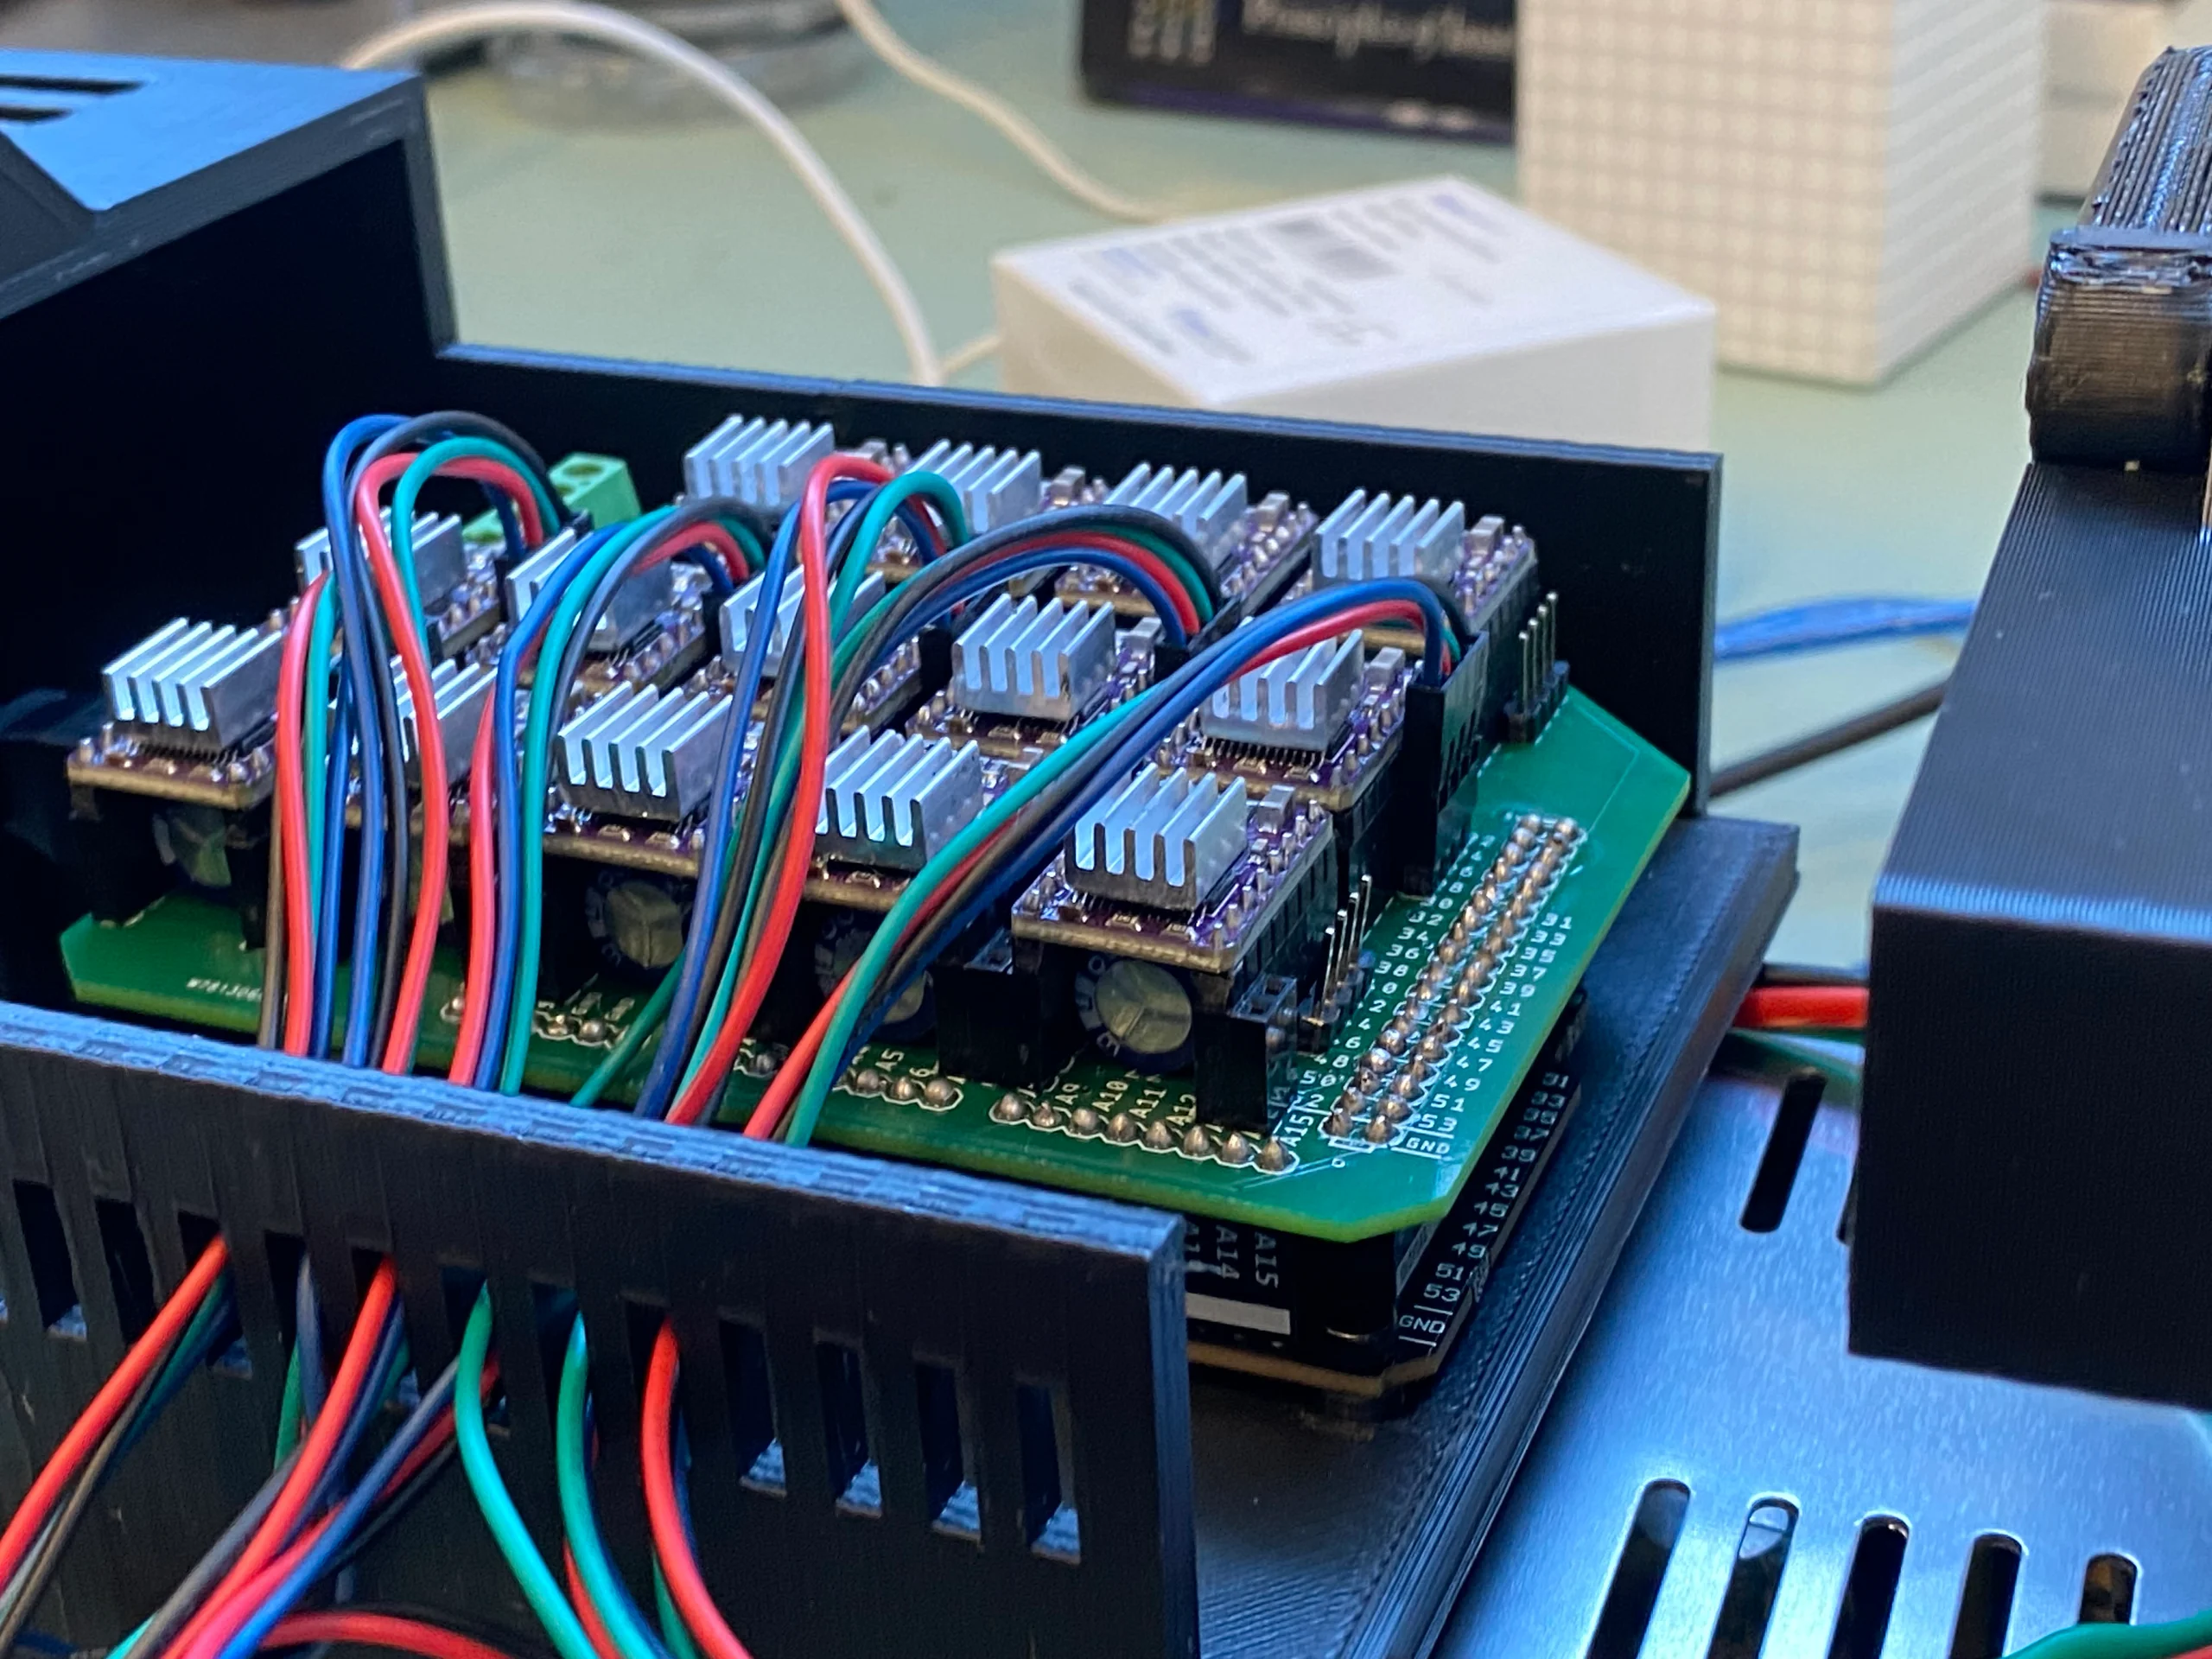
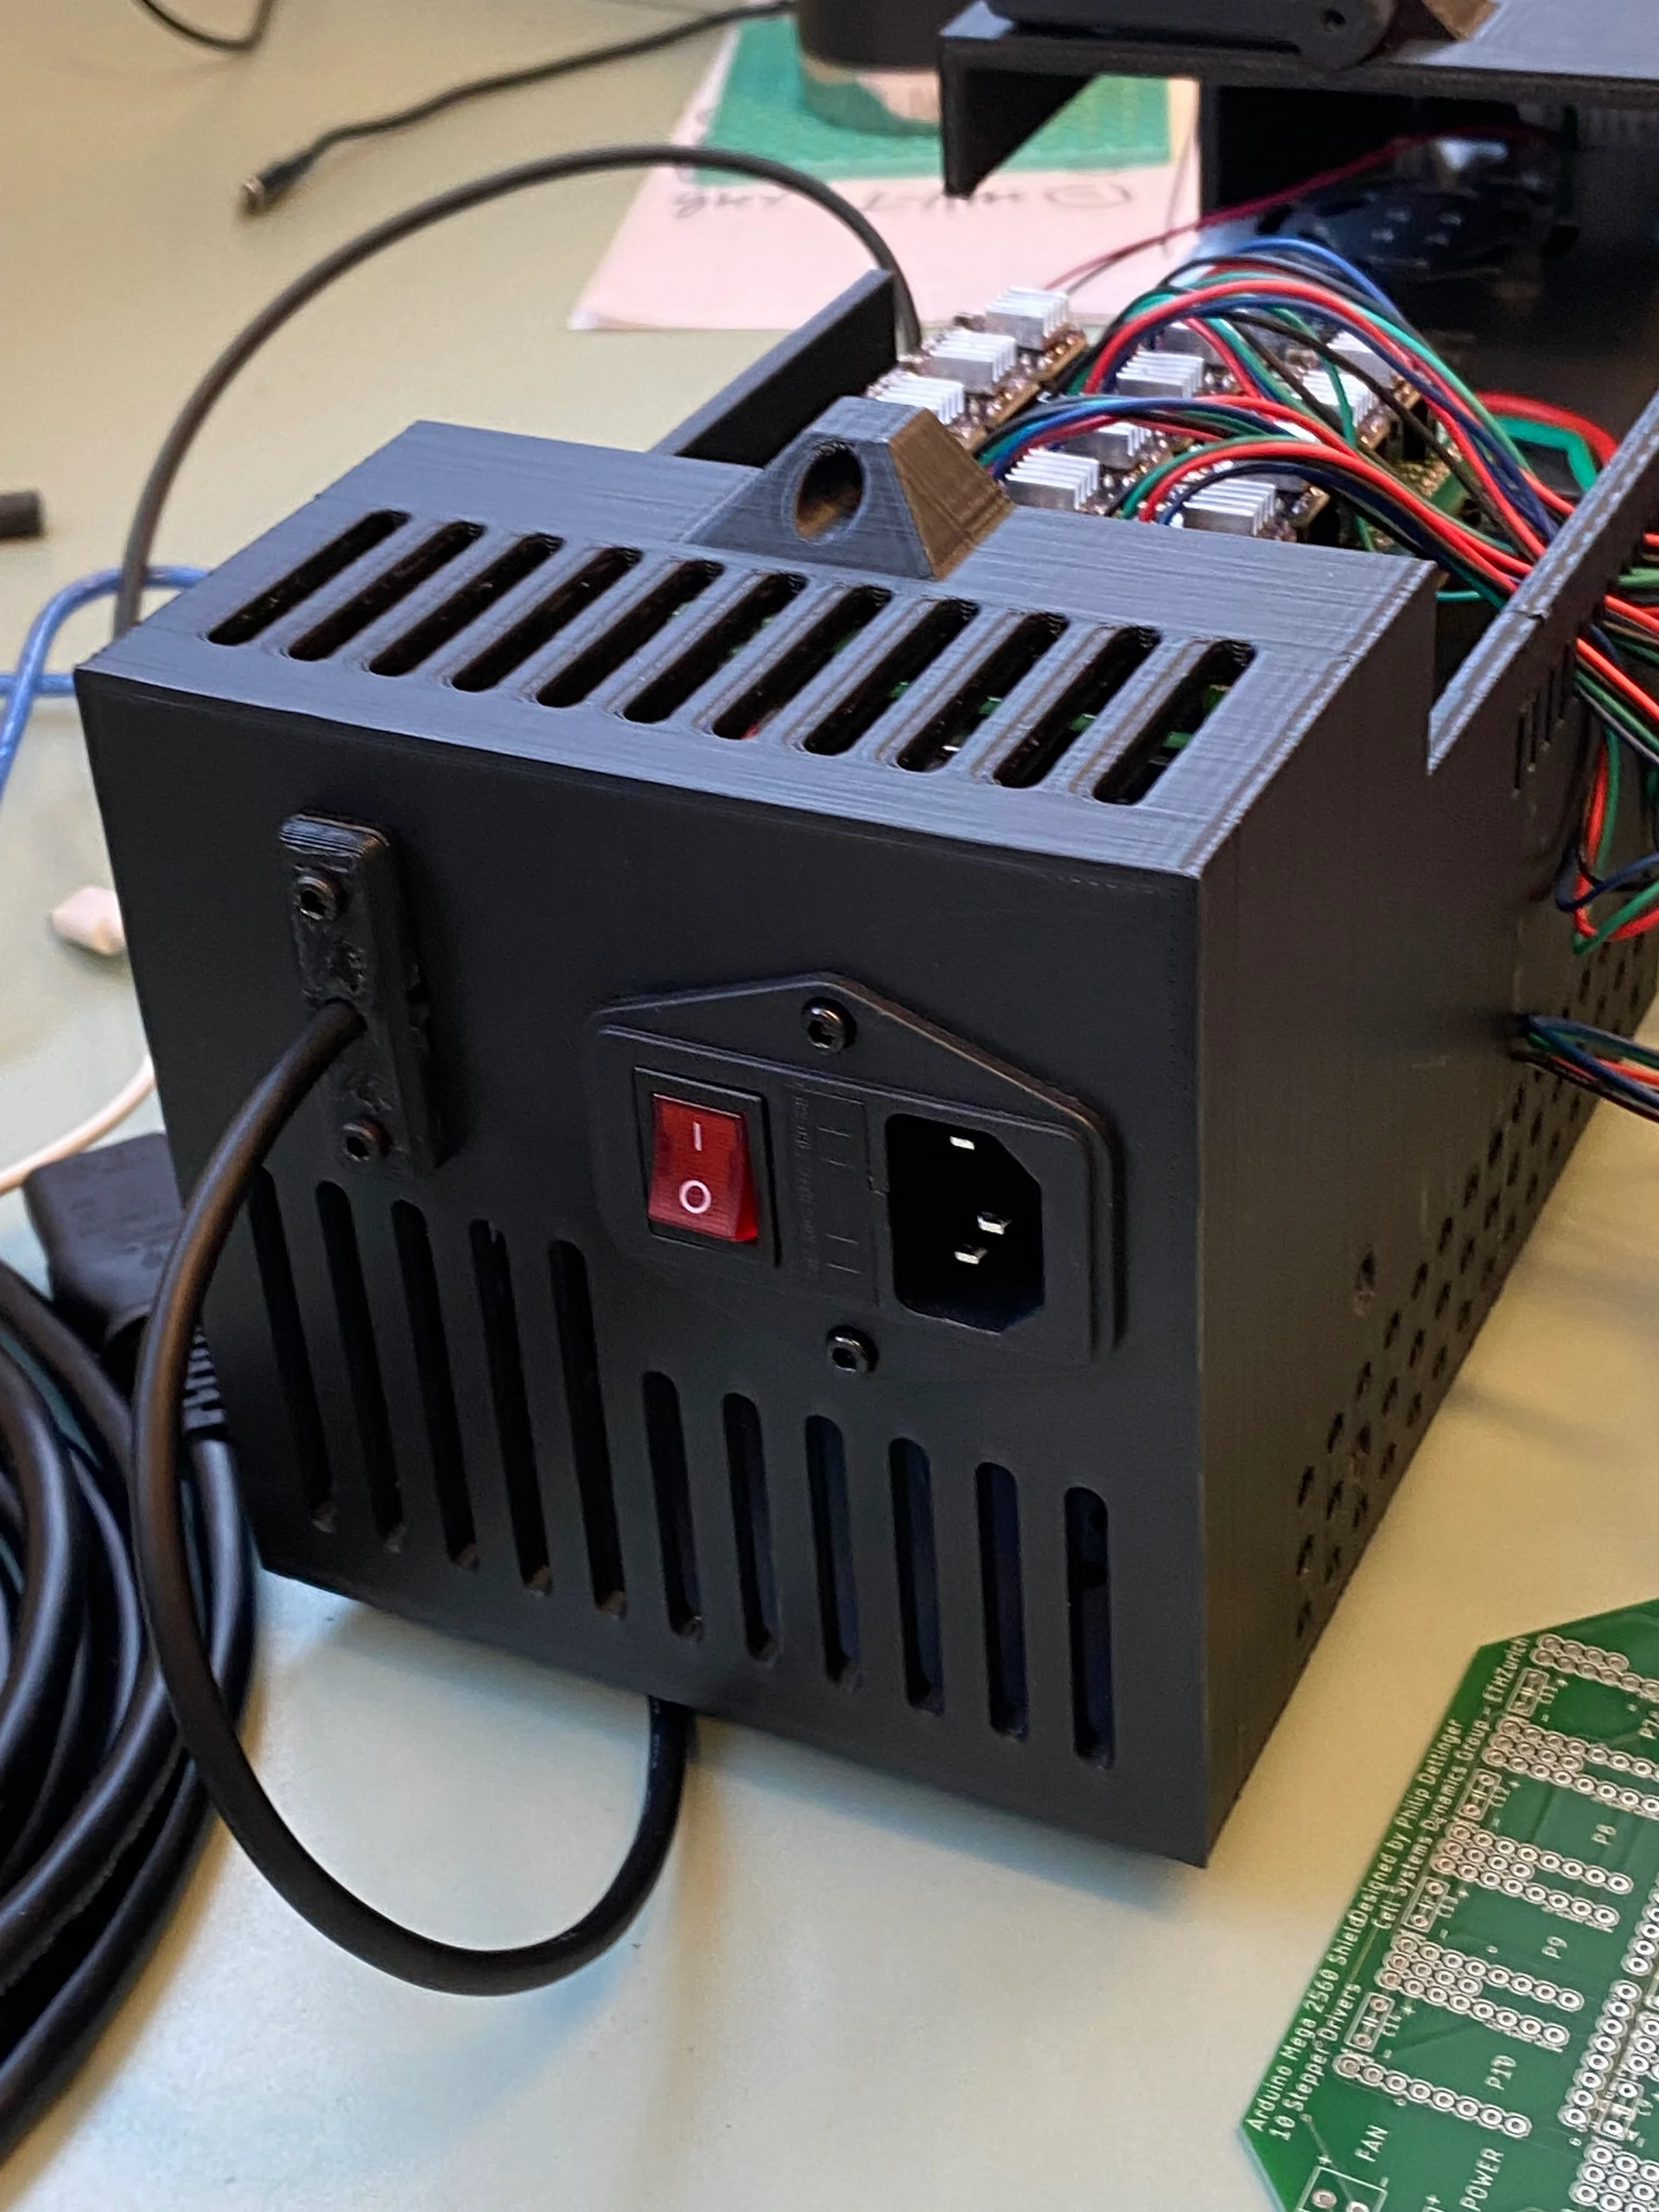
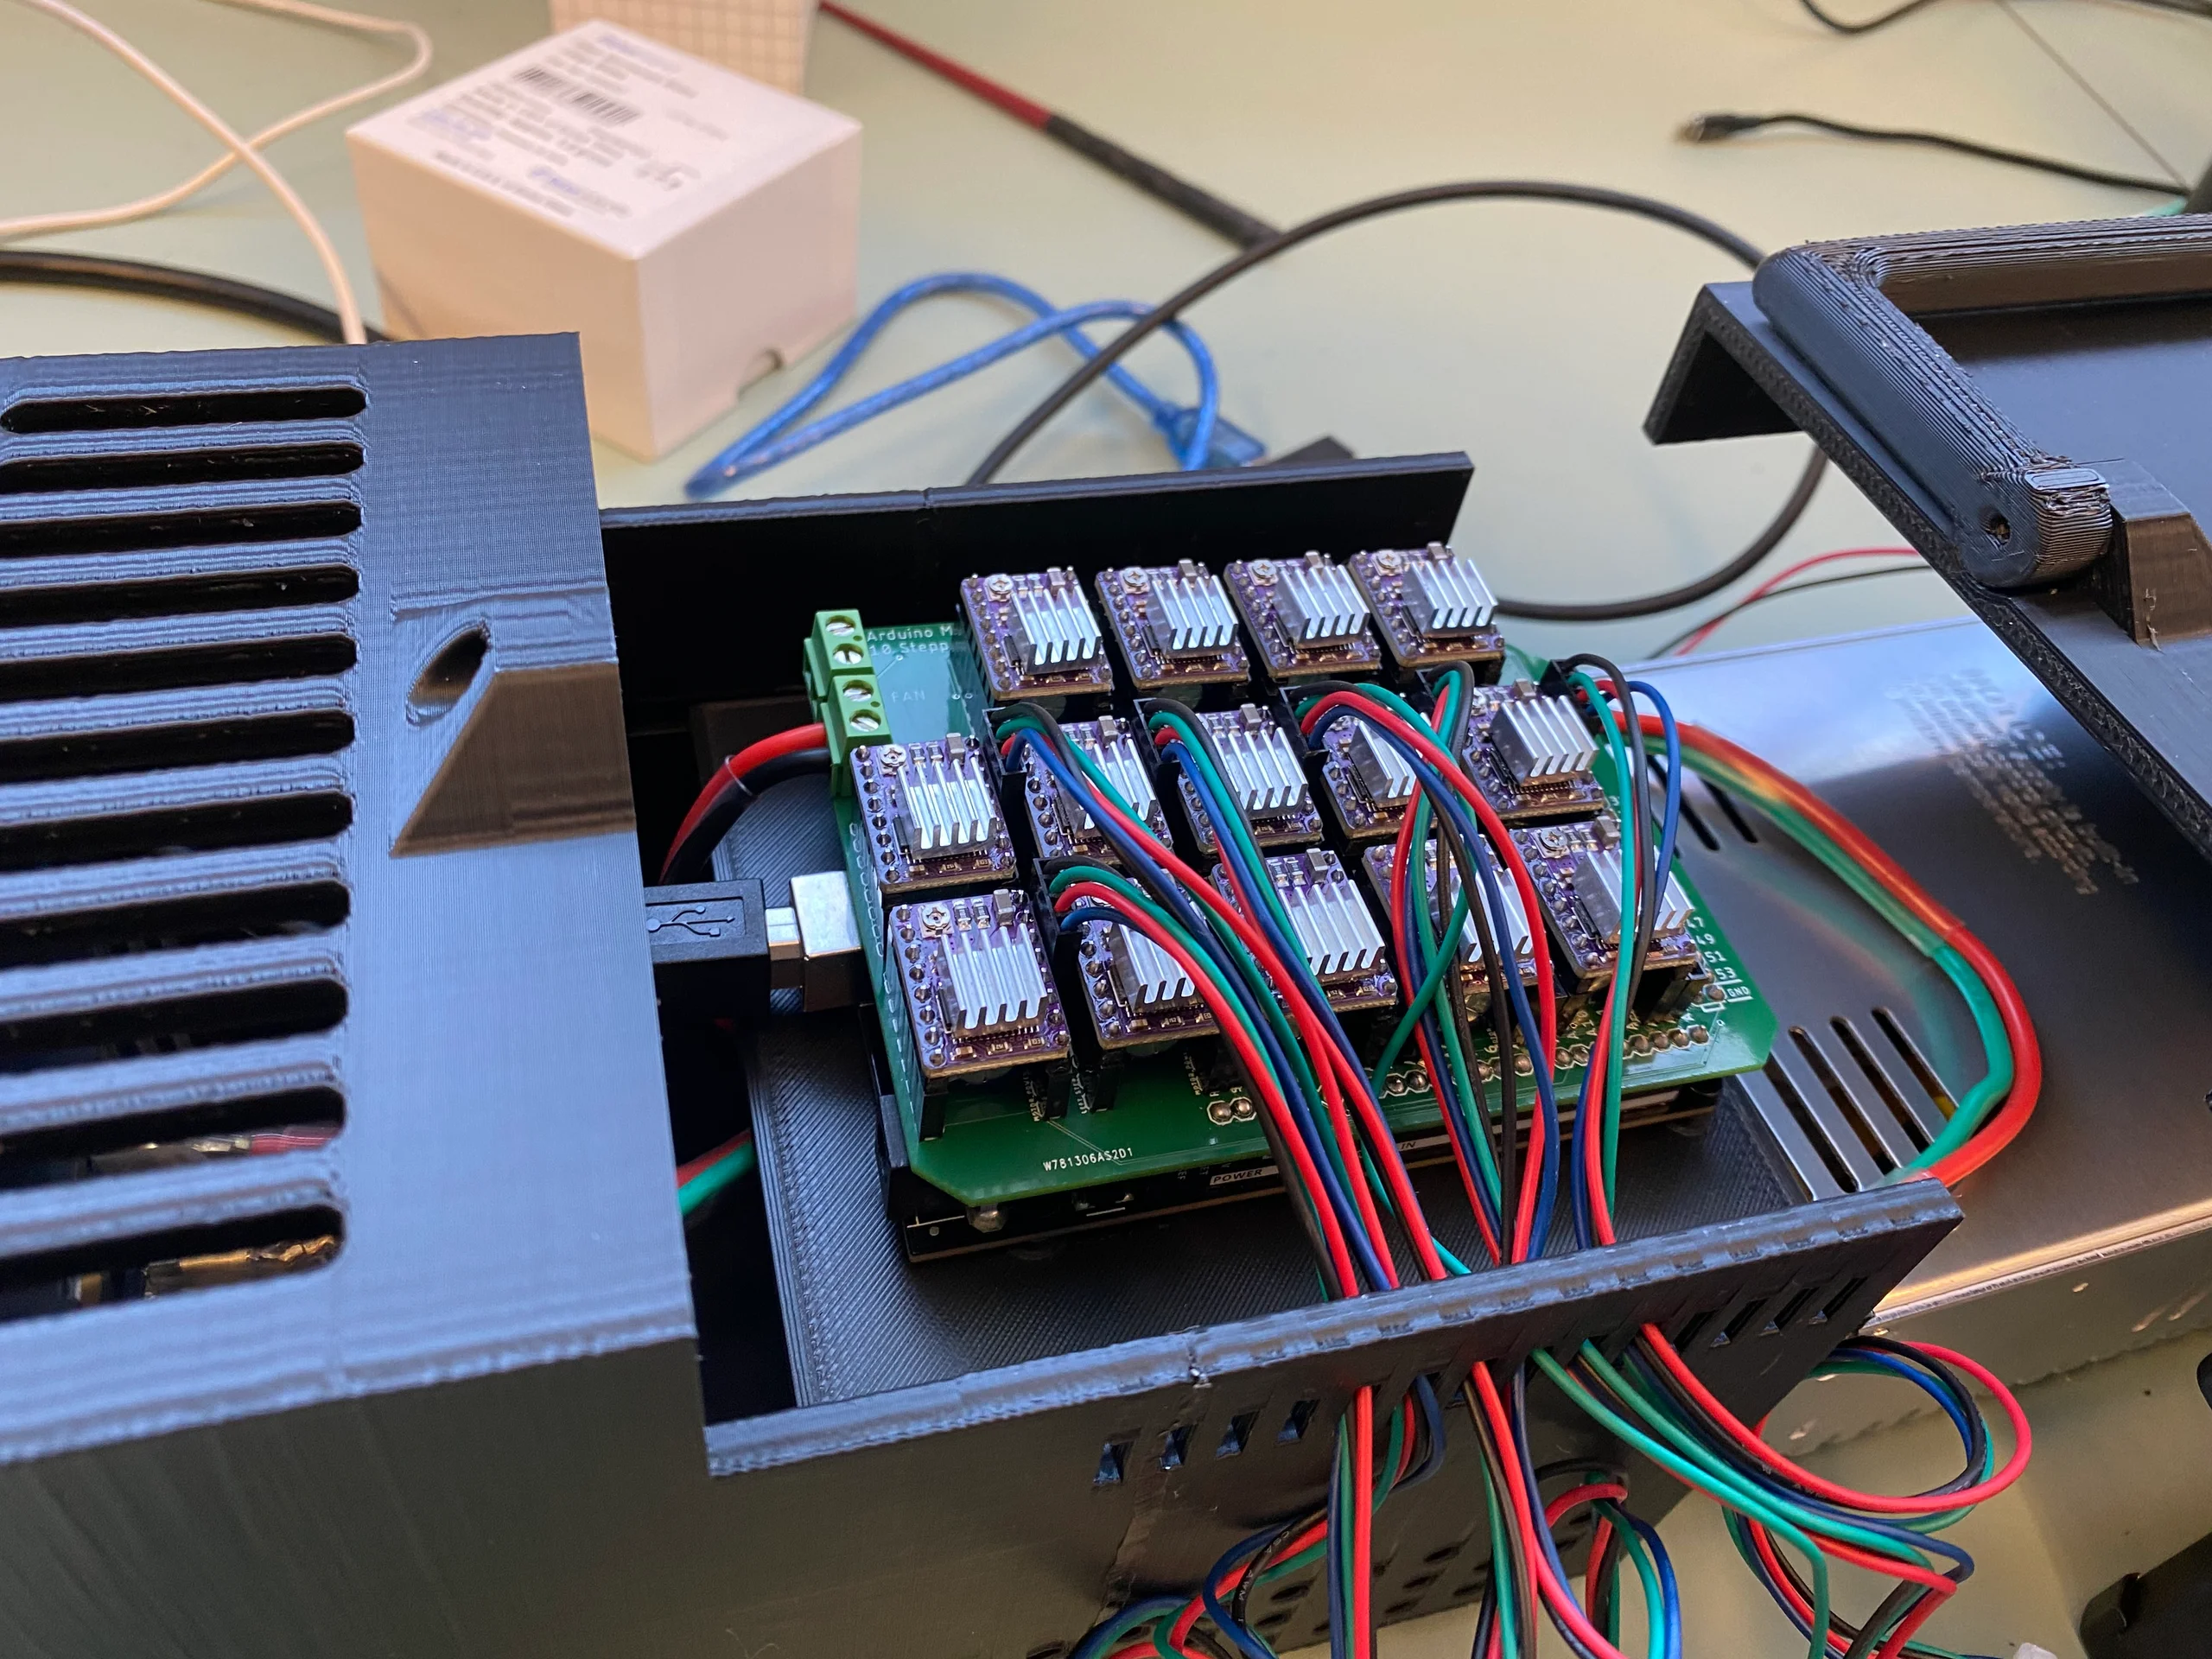
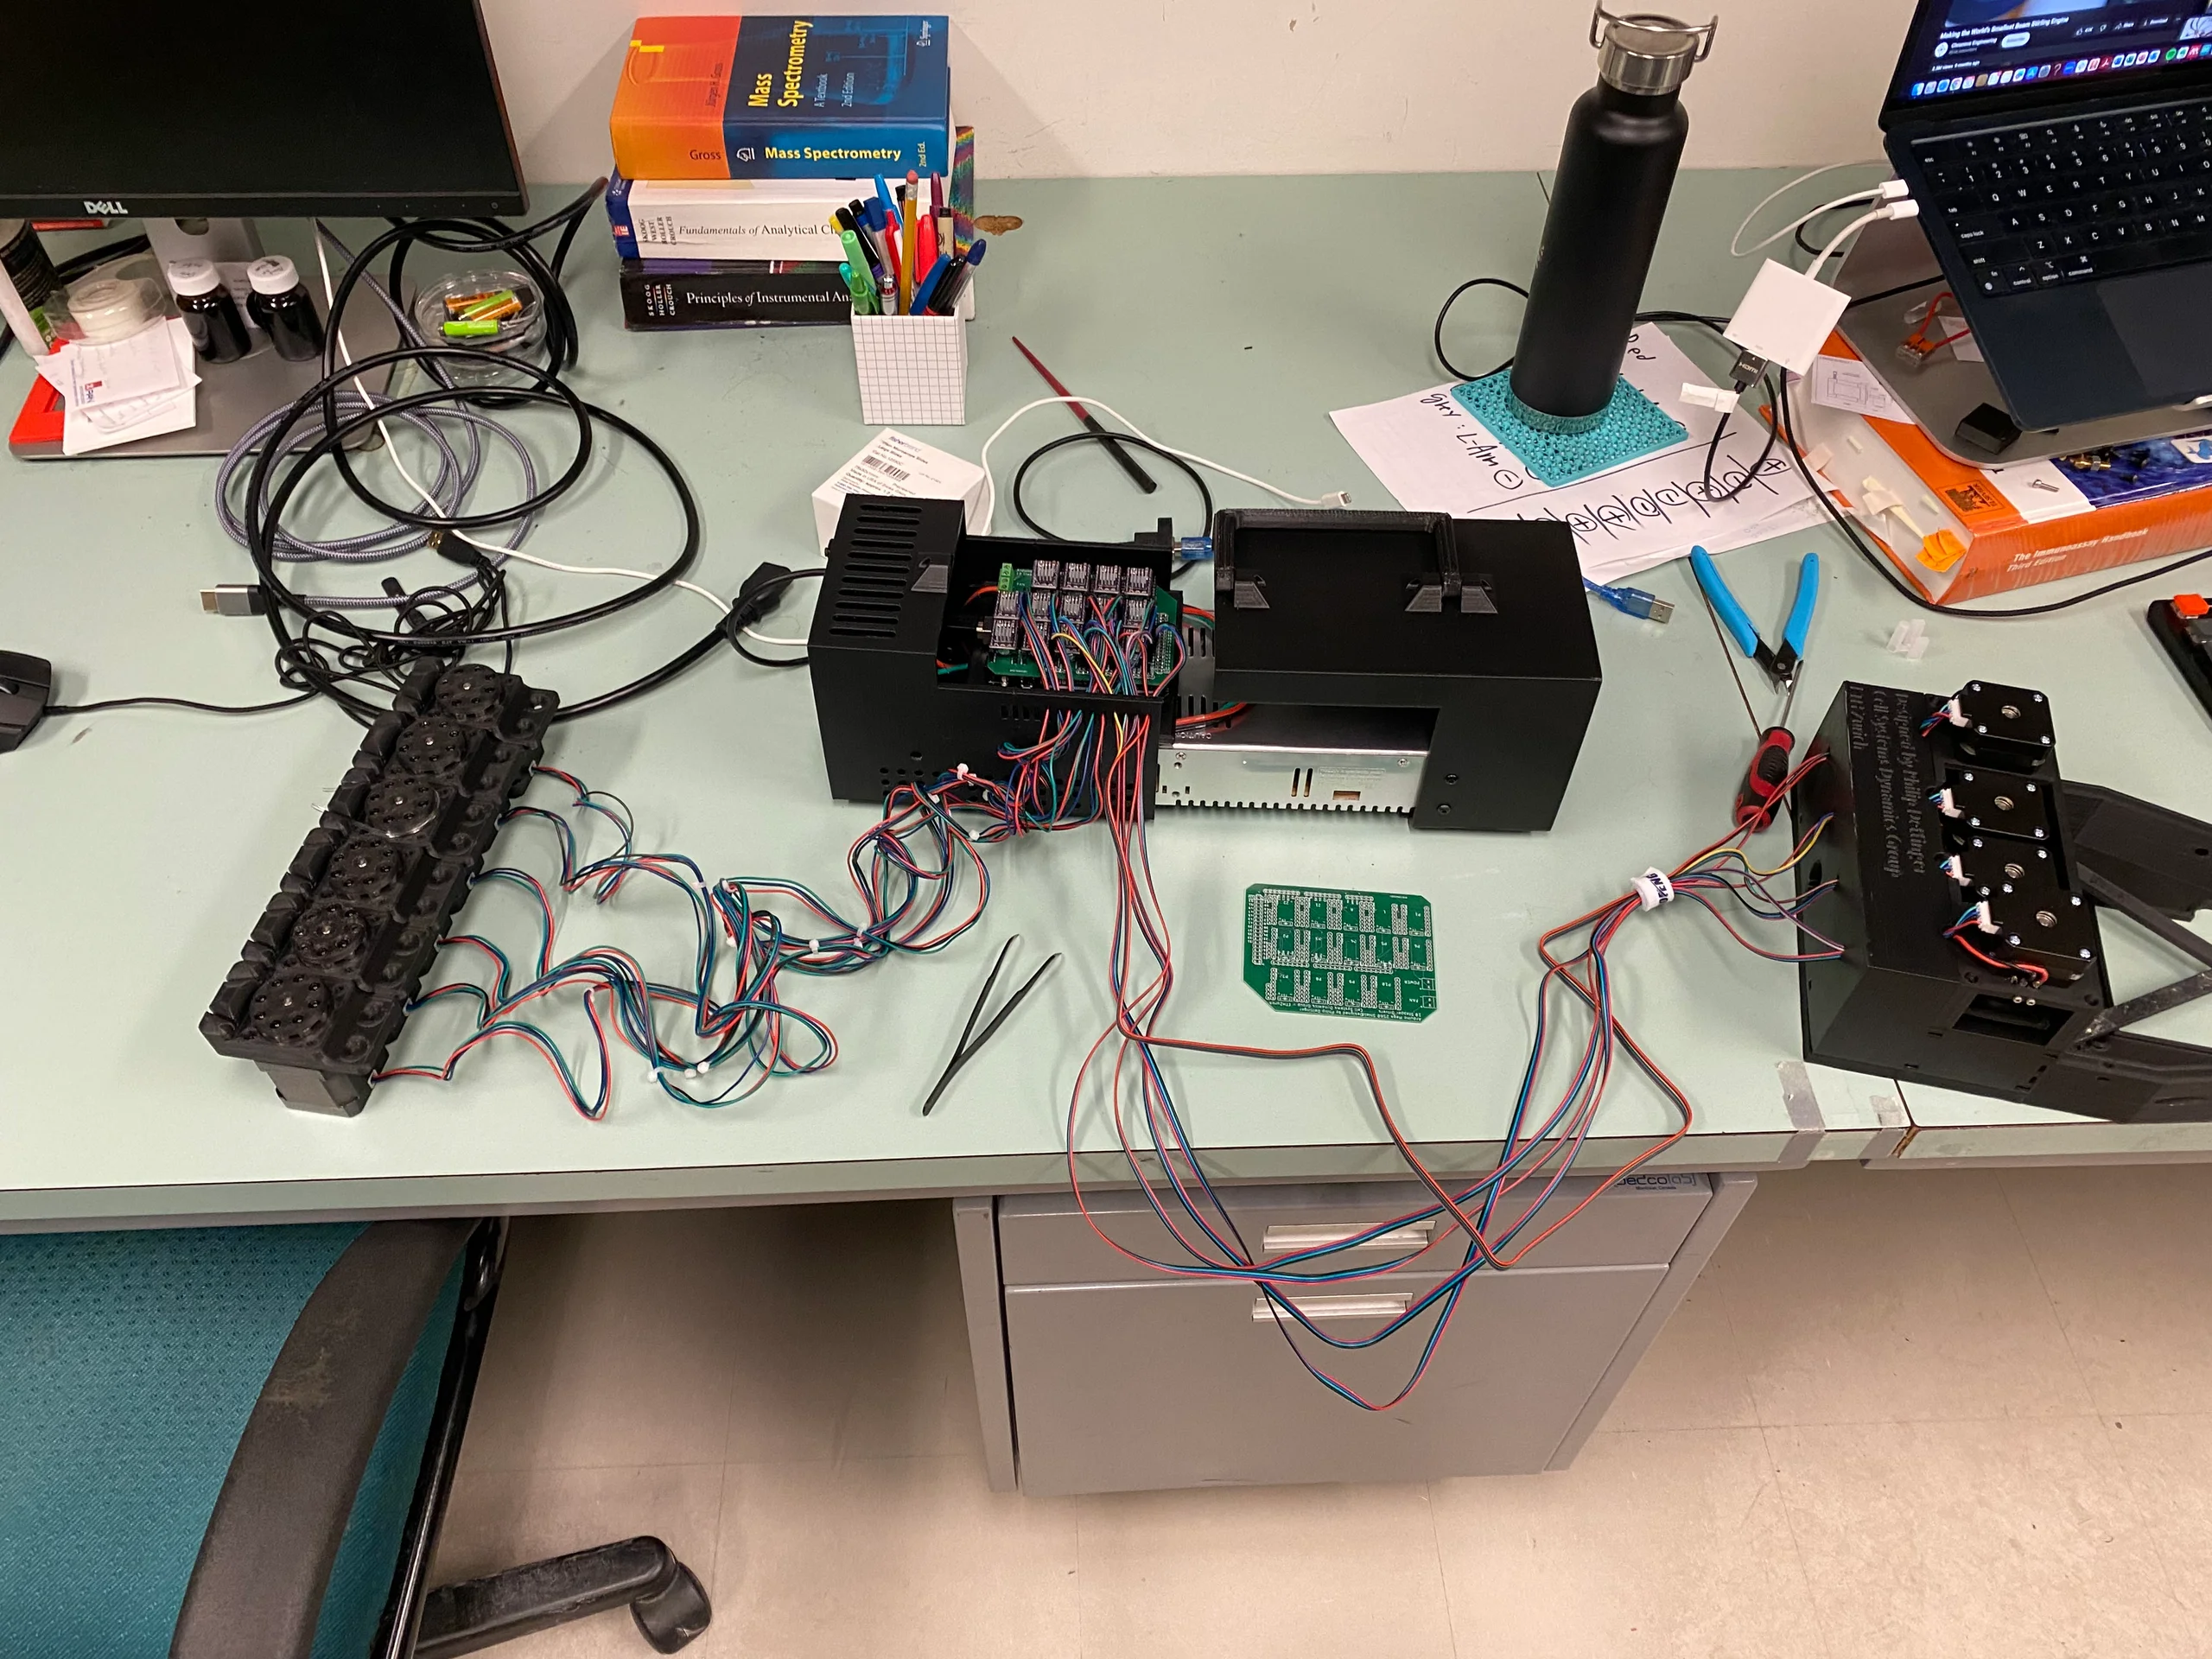
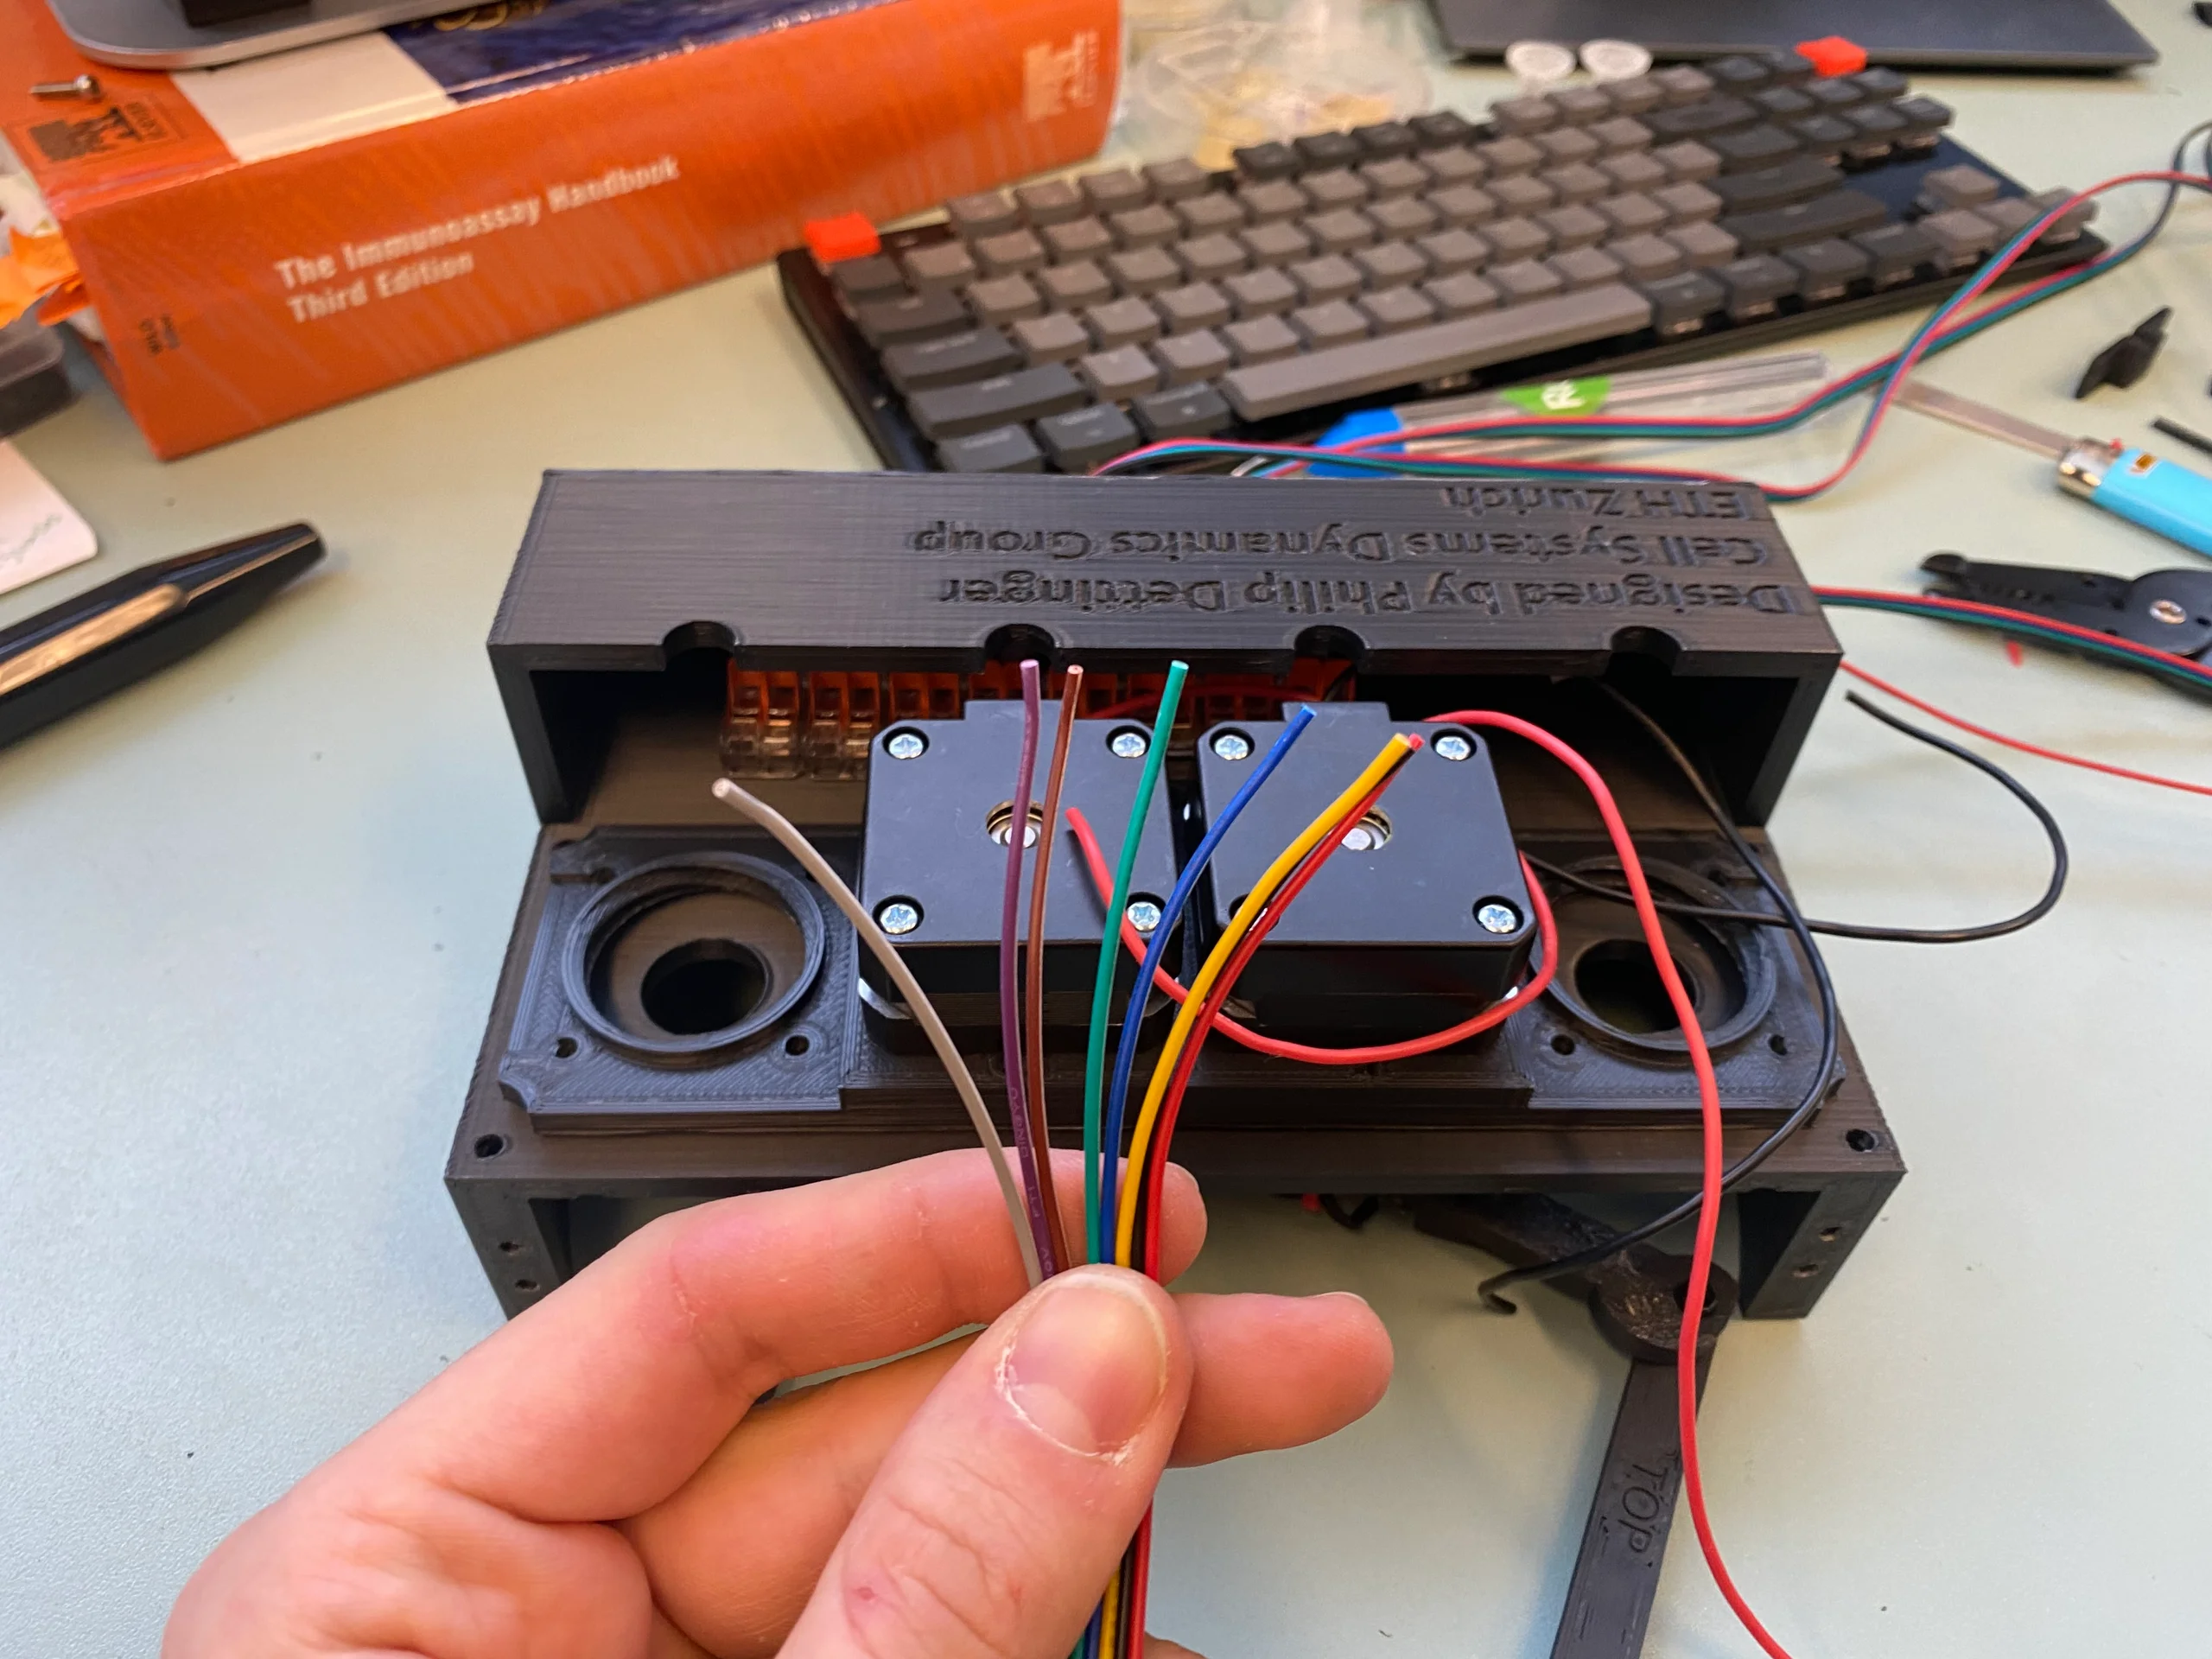
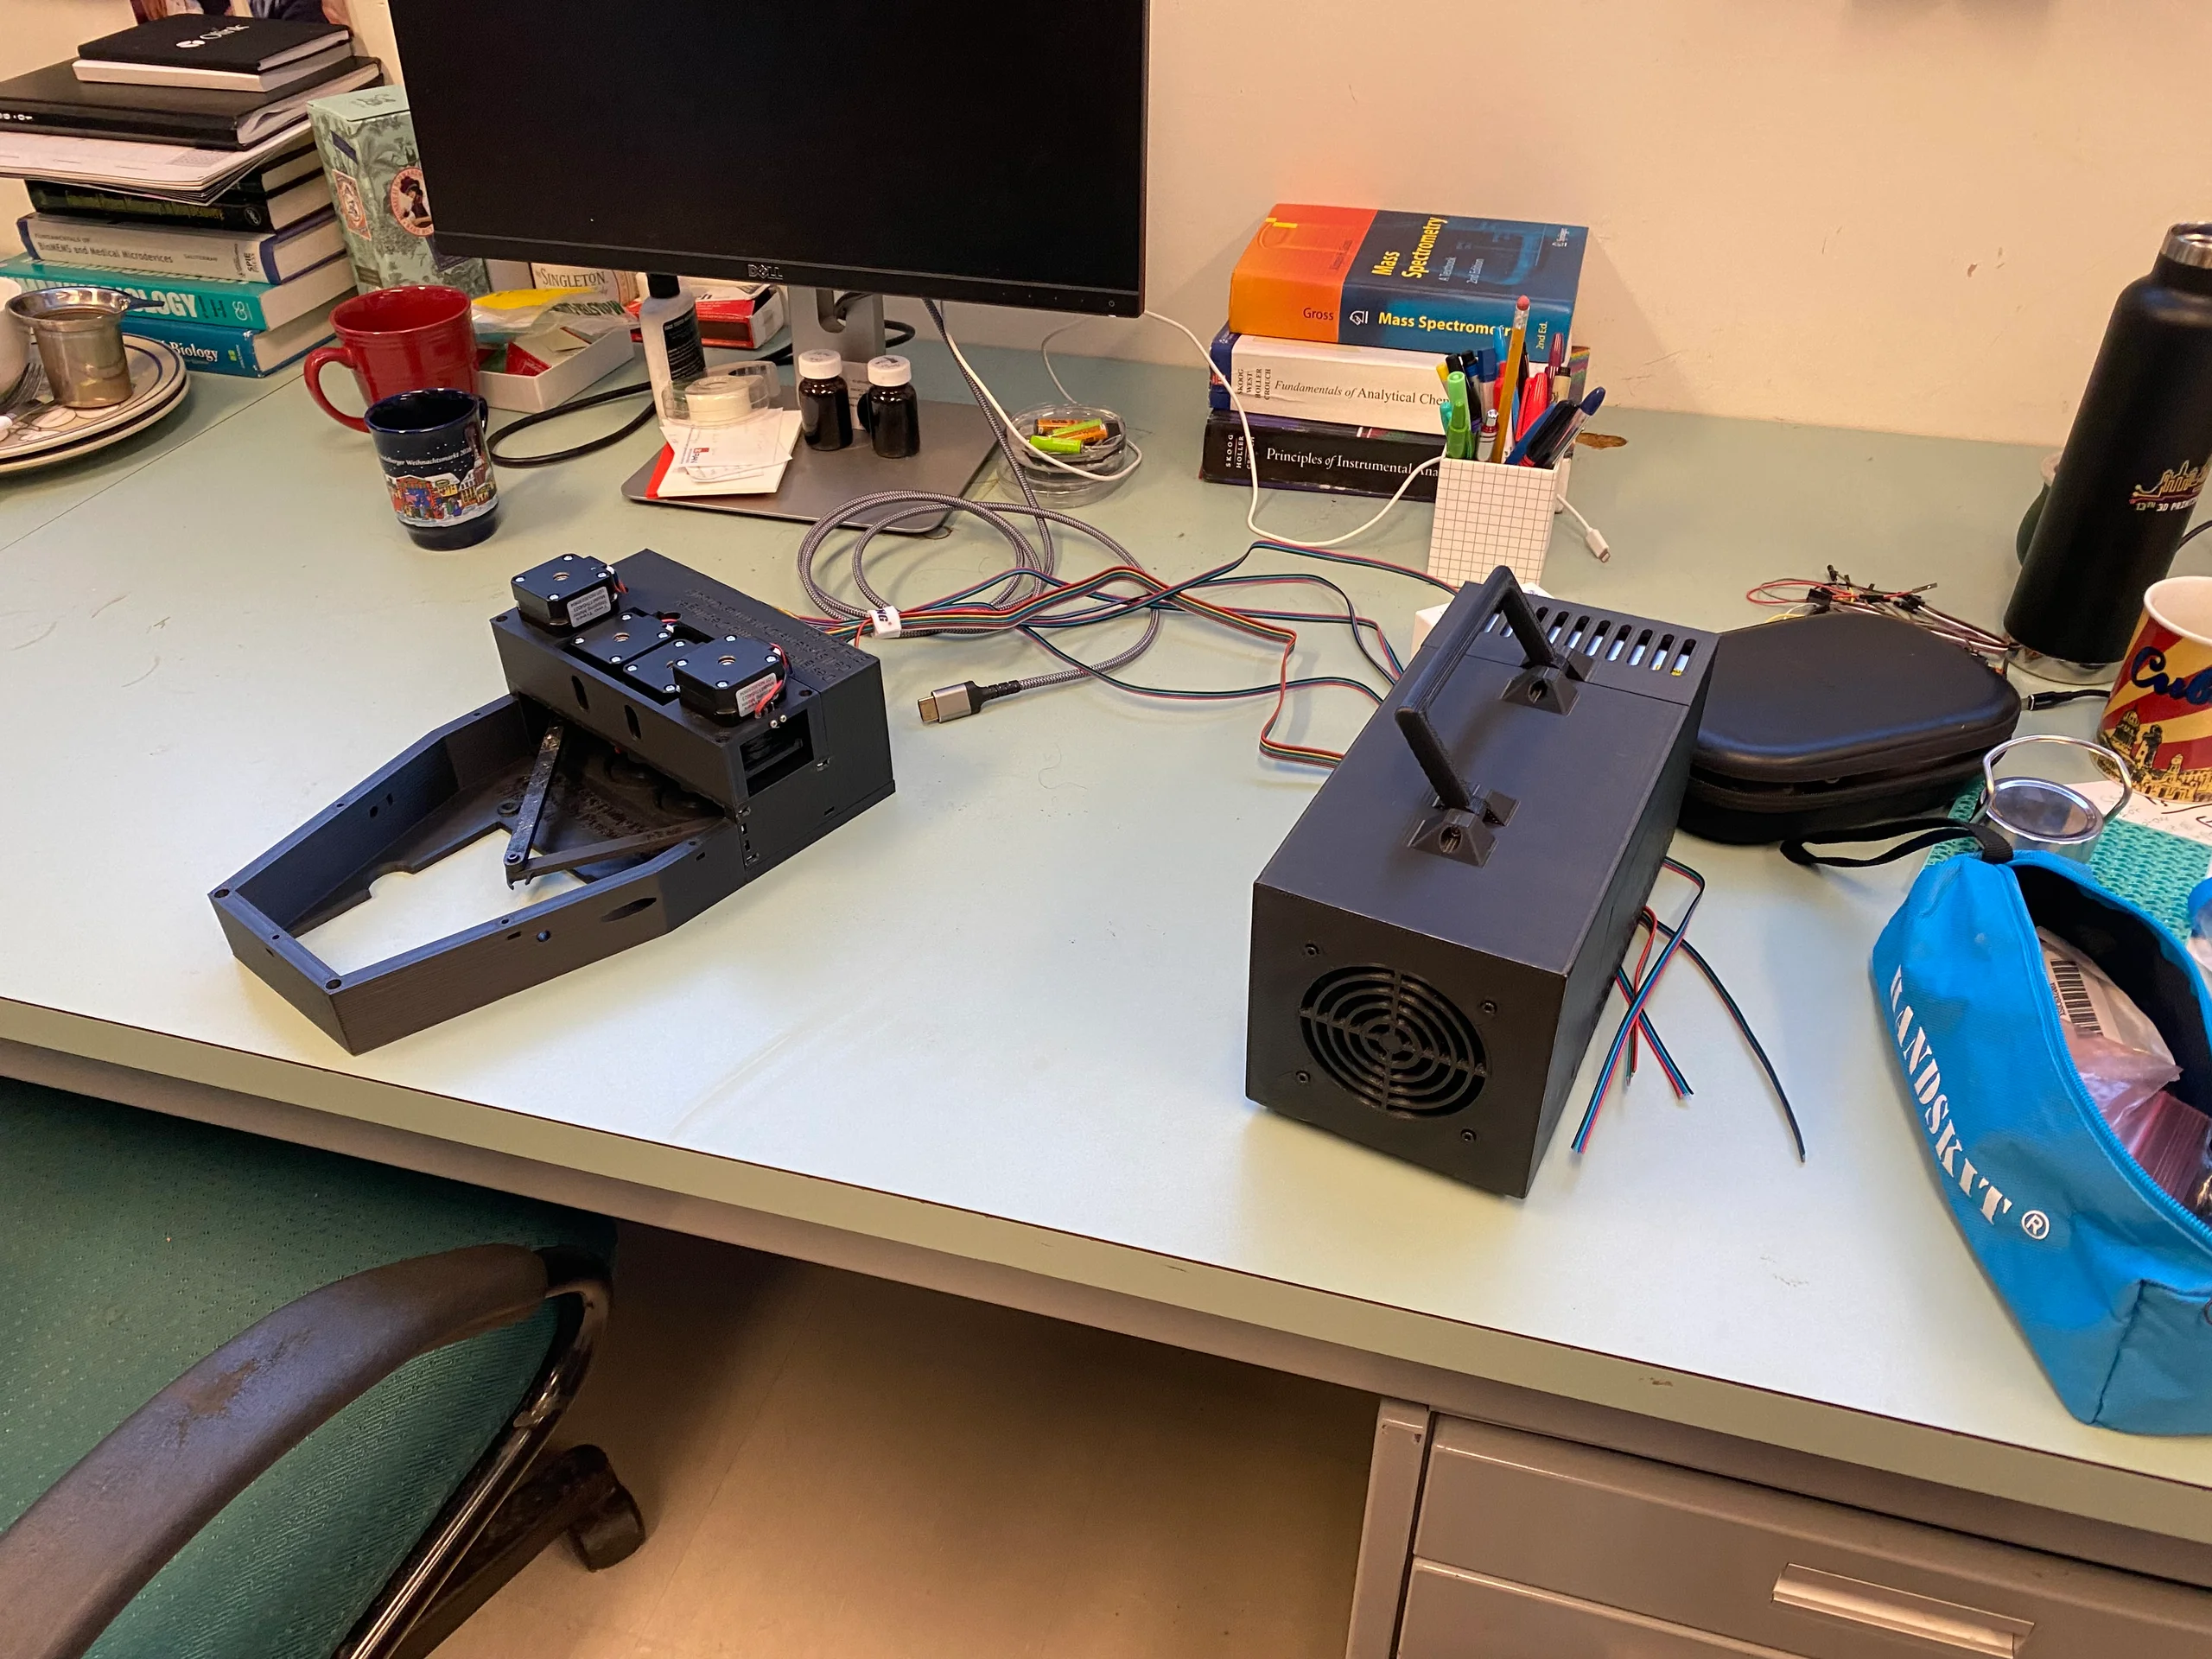
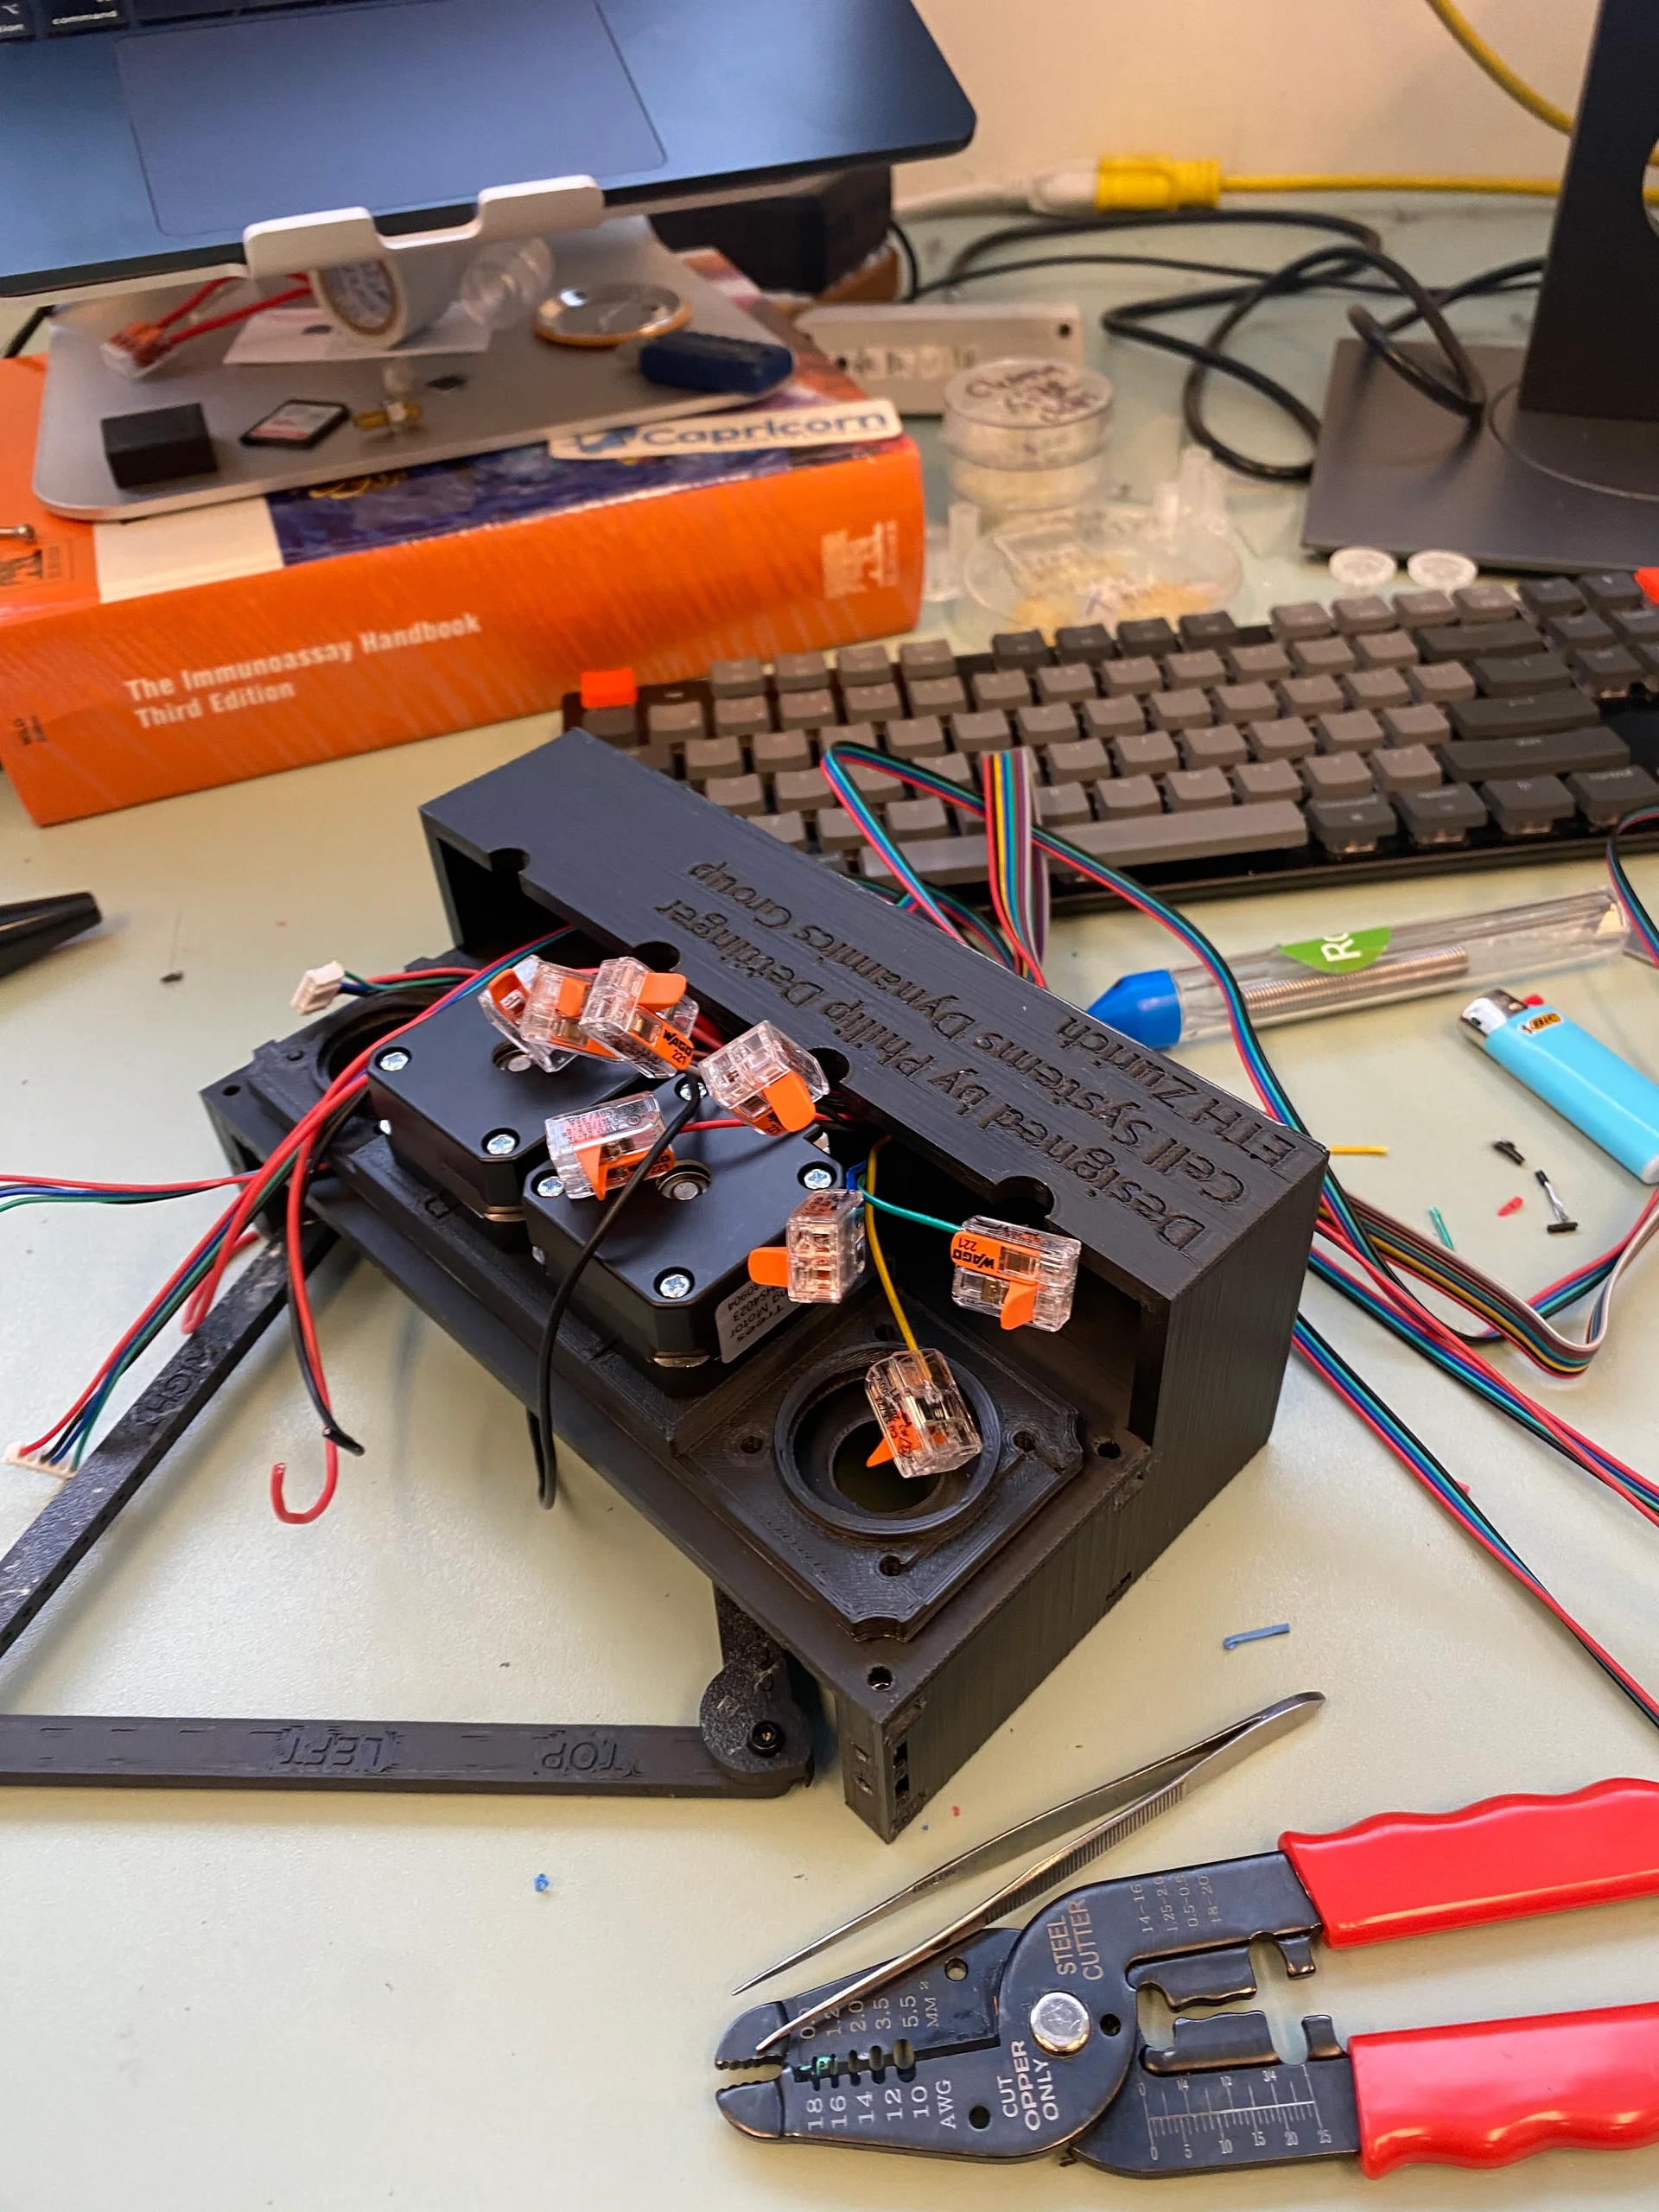
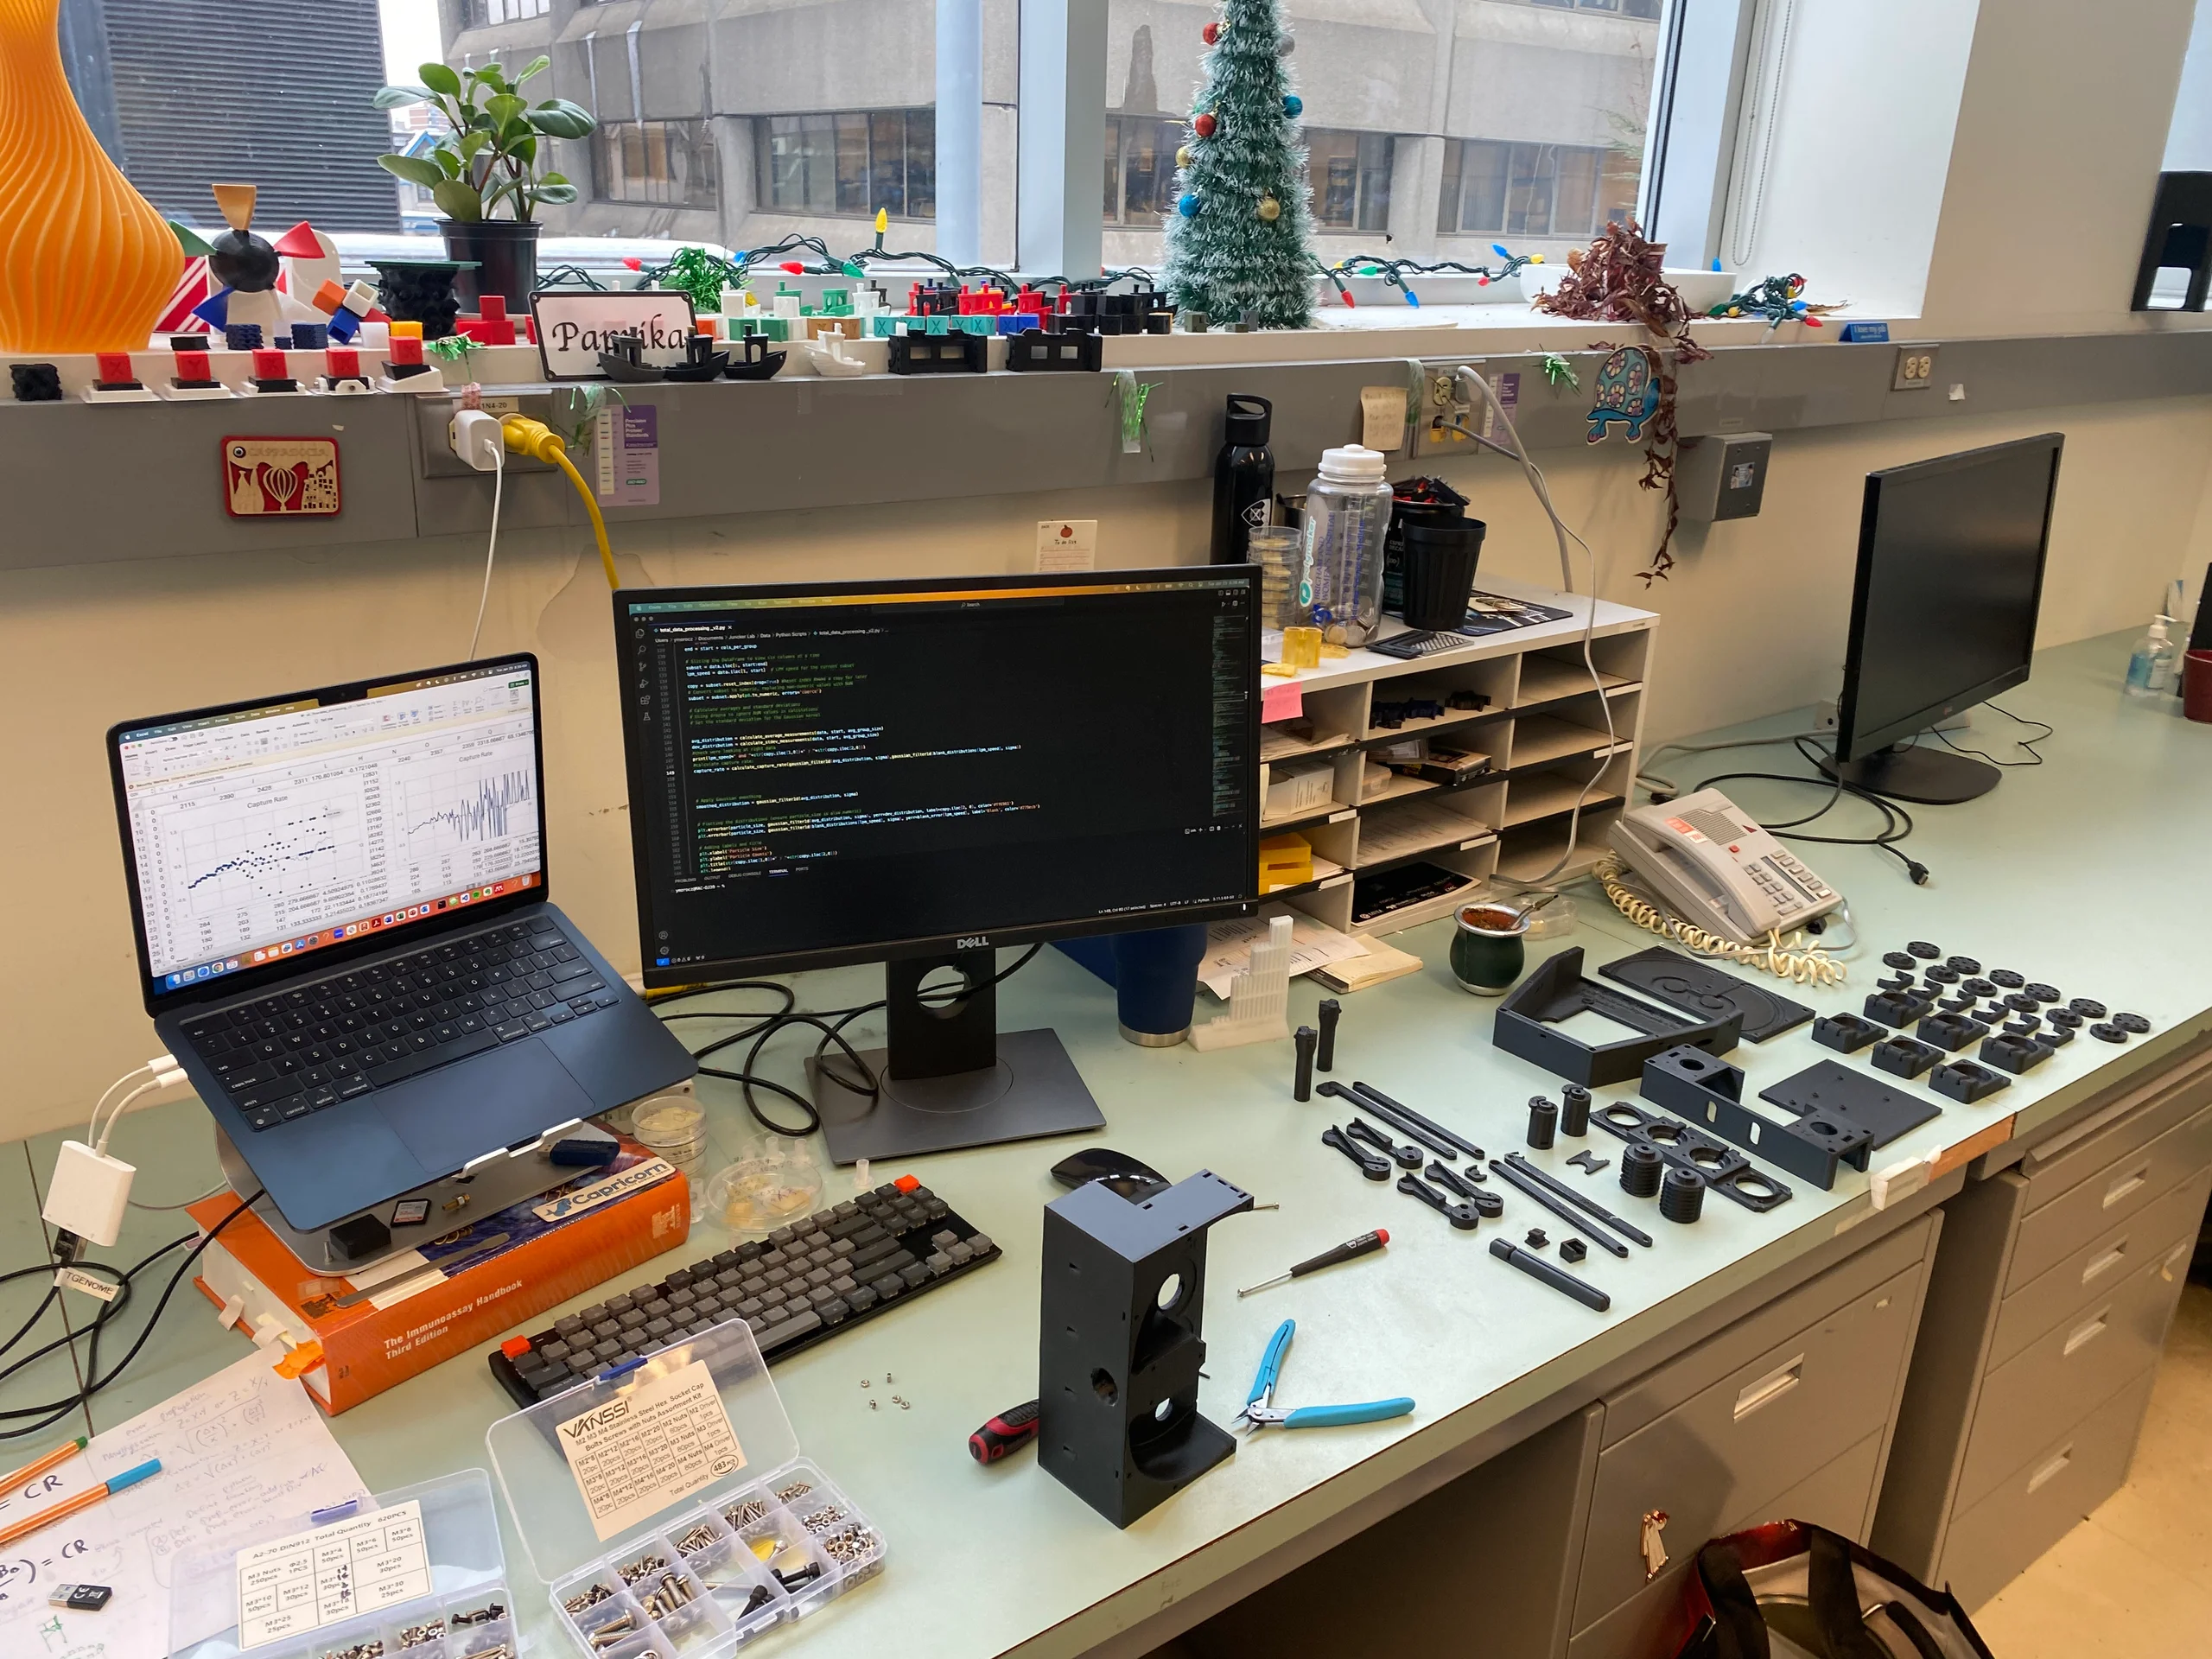
A laboratory robot build based on the open-source PHIL pipetting platform.
On this page01Overview
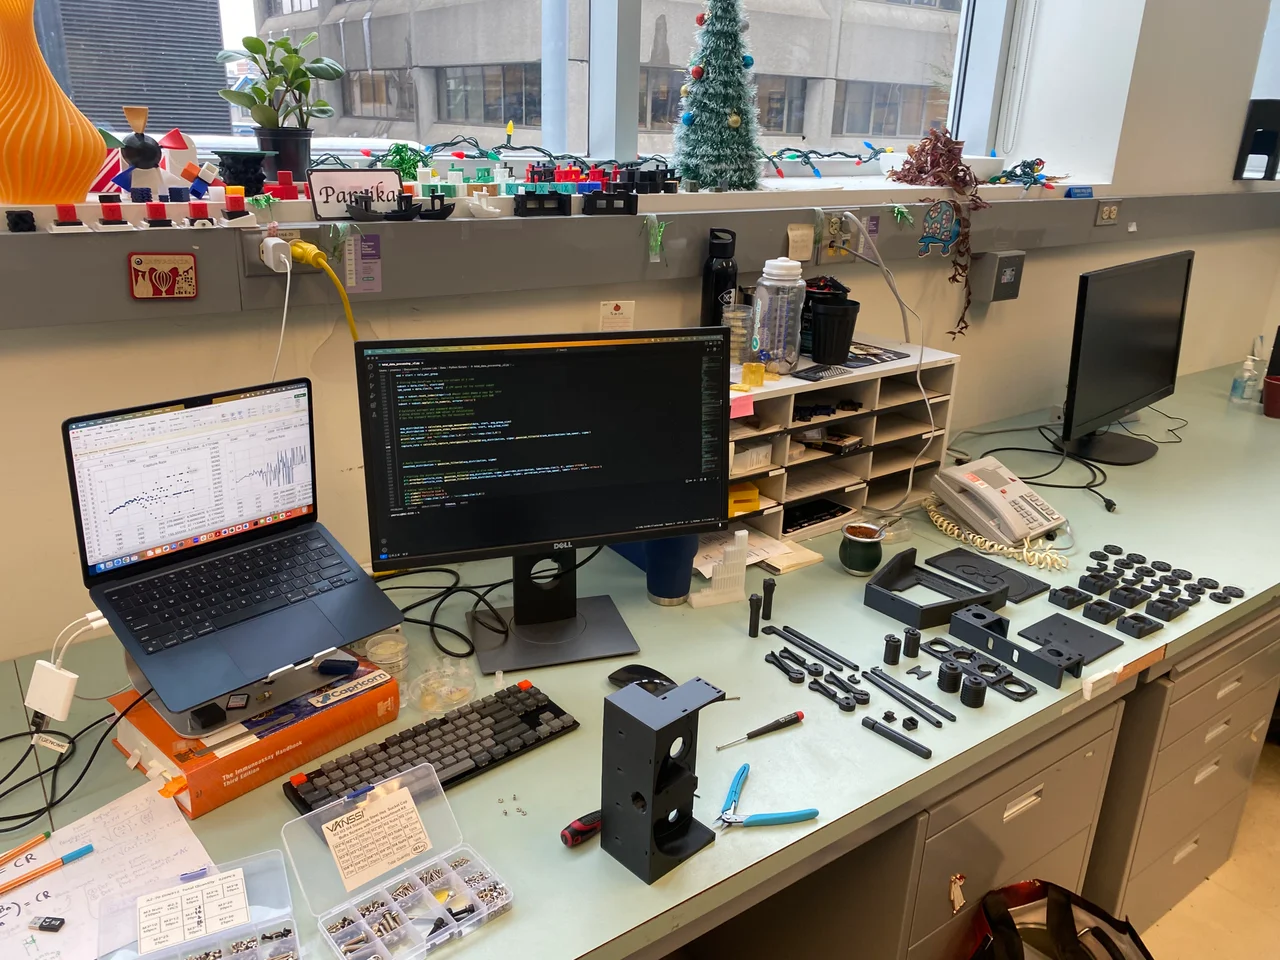
An open-source design, built for the laboratory.
This build is based on the Pipetting Helper Imaging Lid (PHIL), the personal liquid-handling robot described by Dettinger and colleagues. The published design combines commercial and 3D-printable components with custom control software.[1]
Pipetting hardware and the electronics behind it.
PHIL uses 3D-printed peristaltic pumps for liquid handling and is designed to work alongside live-cell incubation and microscopy.[1]
Project archive / 11 photos · 1 videos
The complete project archive.
01 / 12
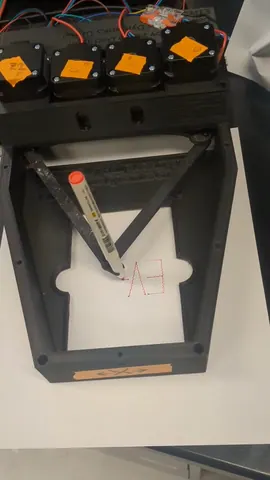
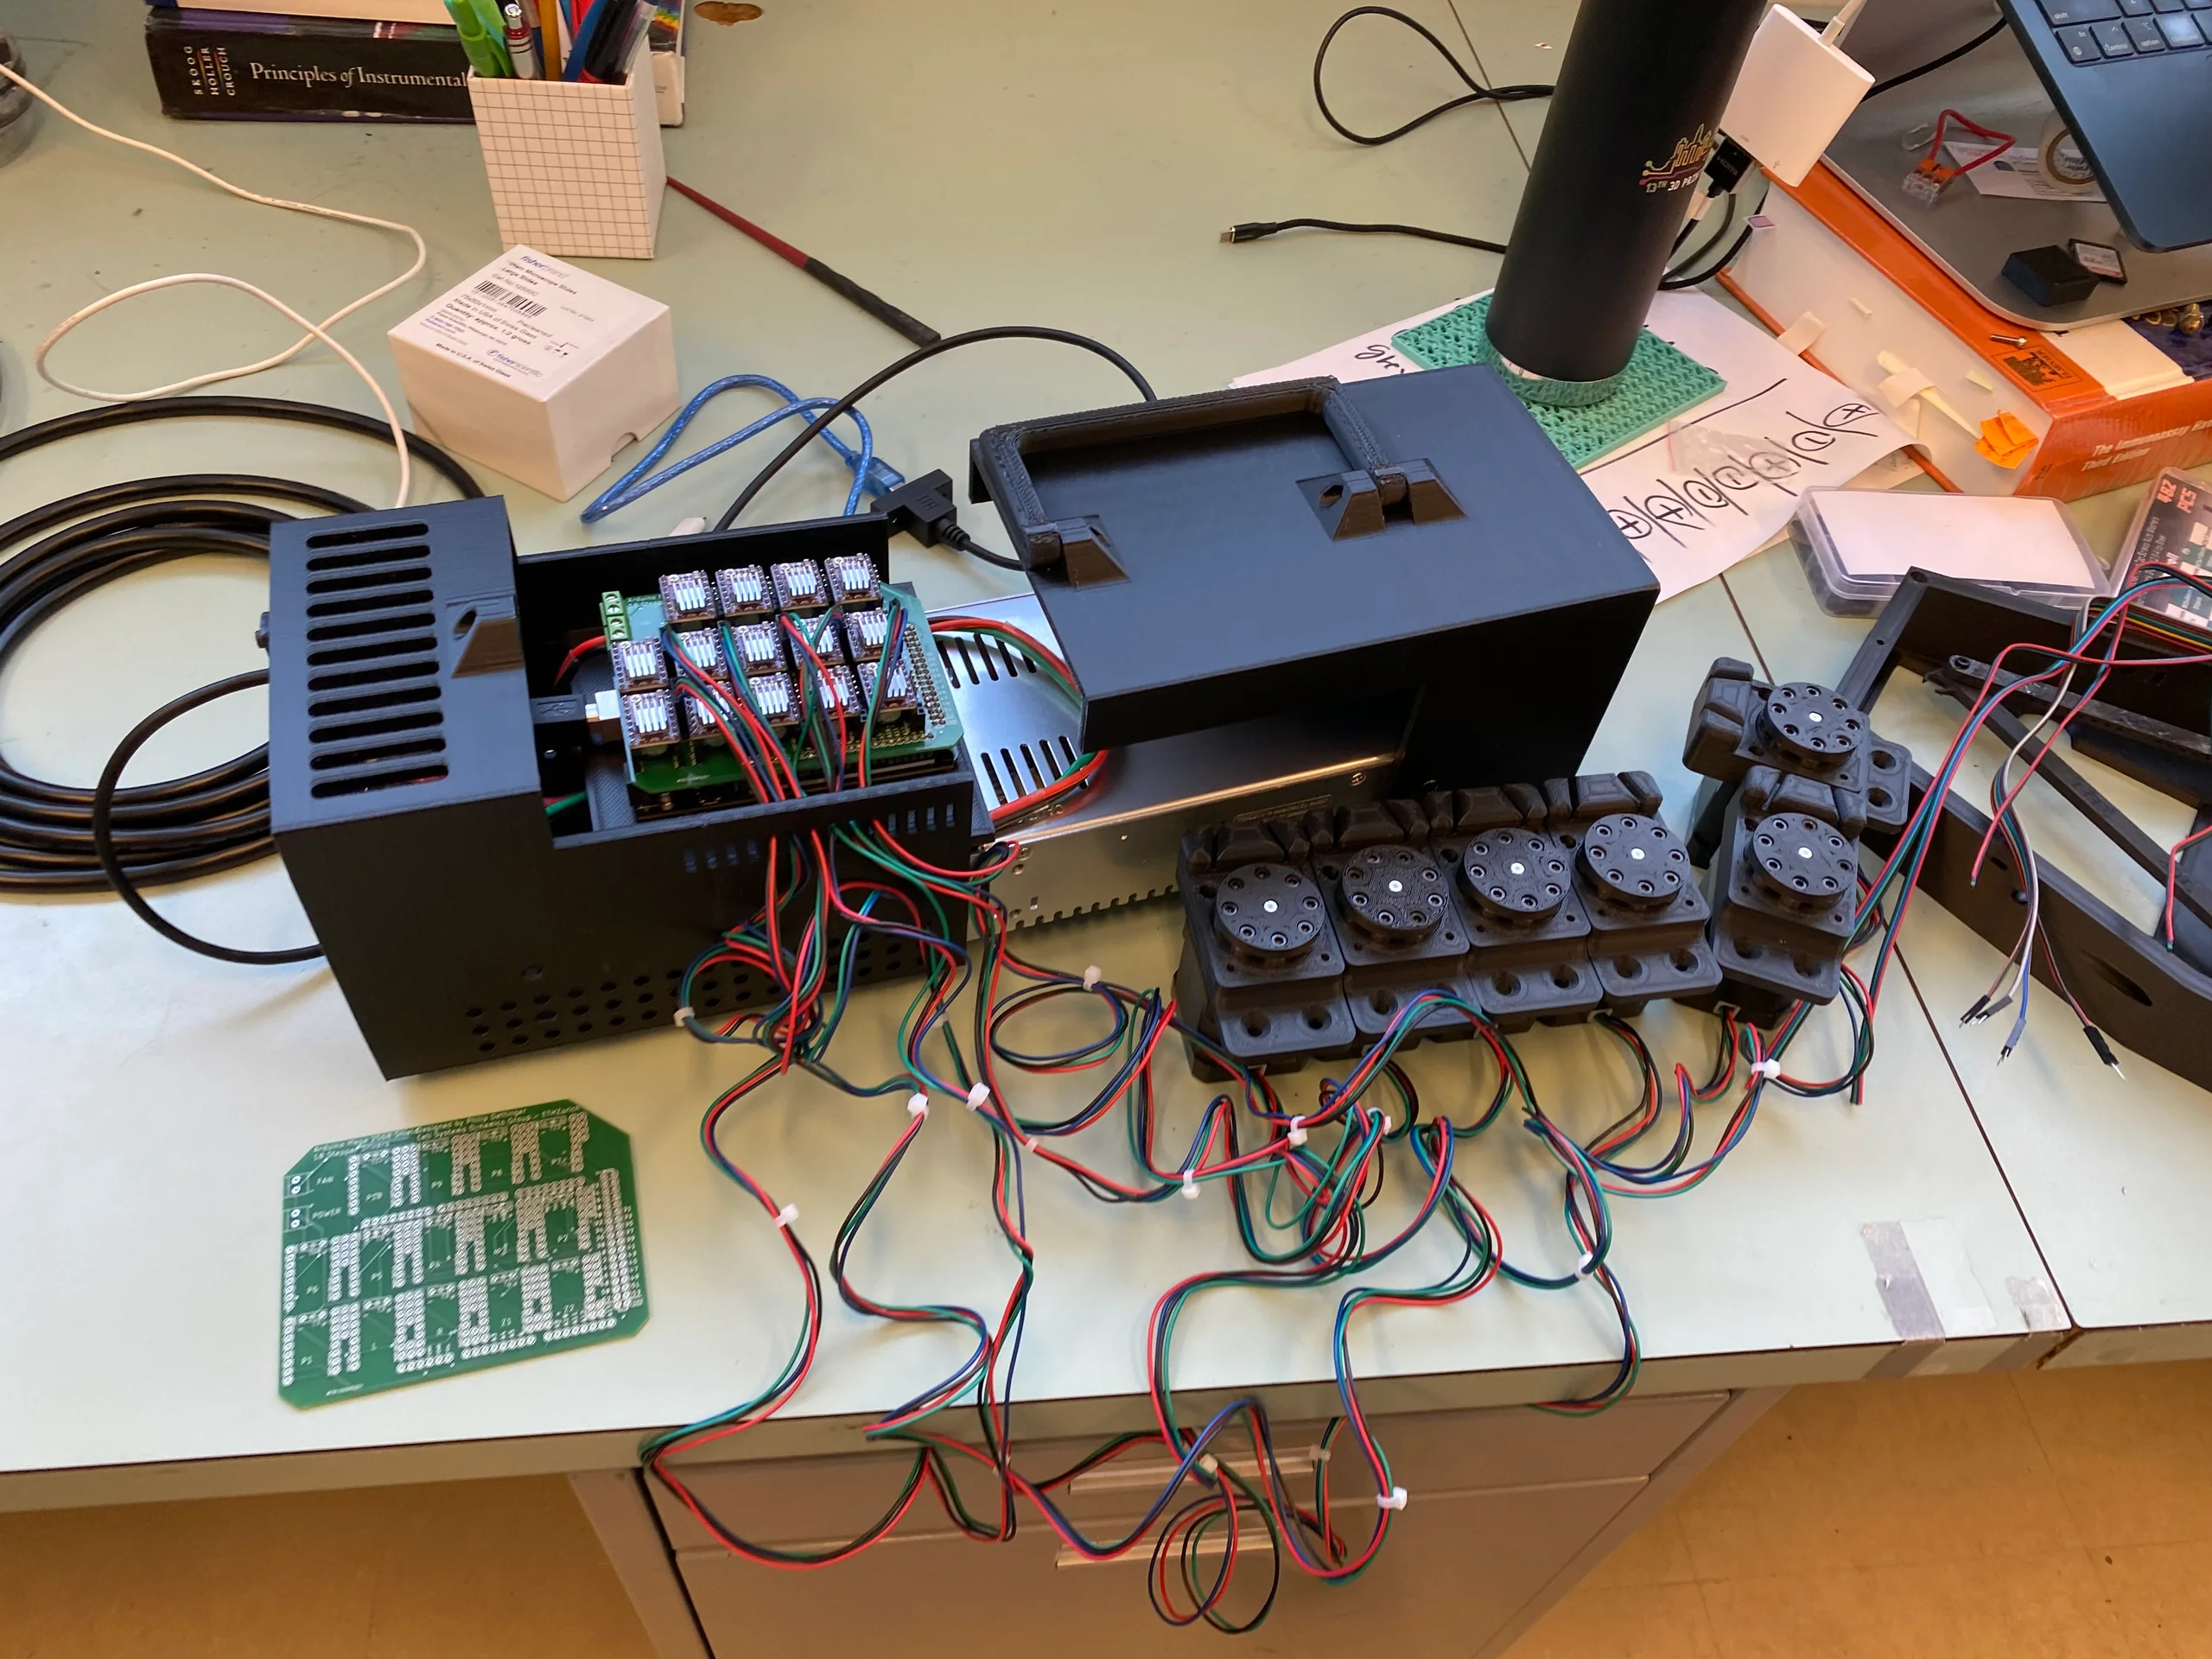
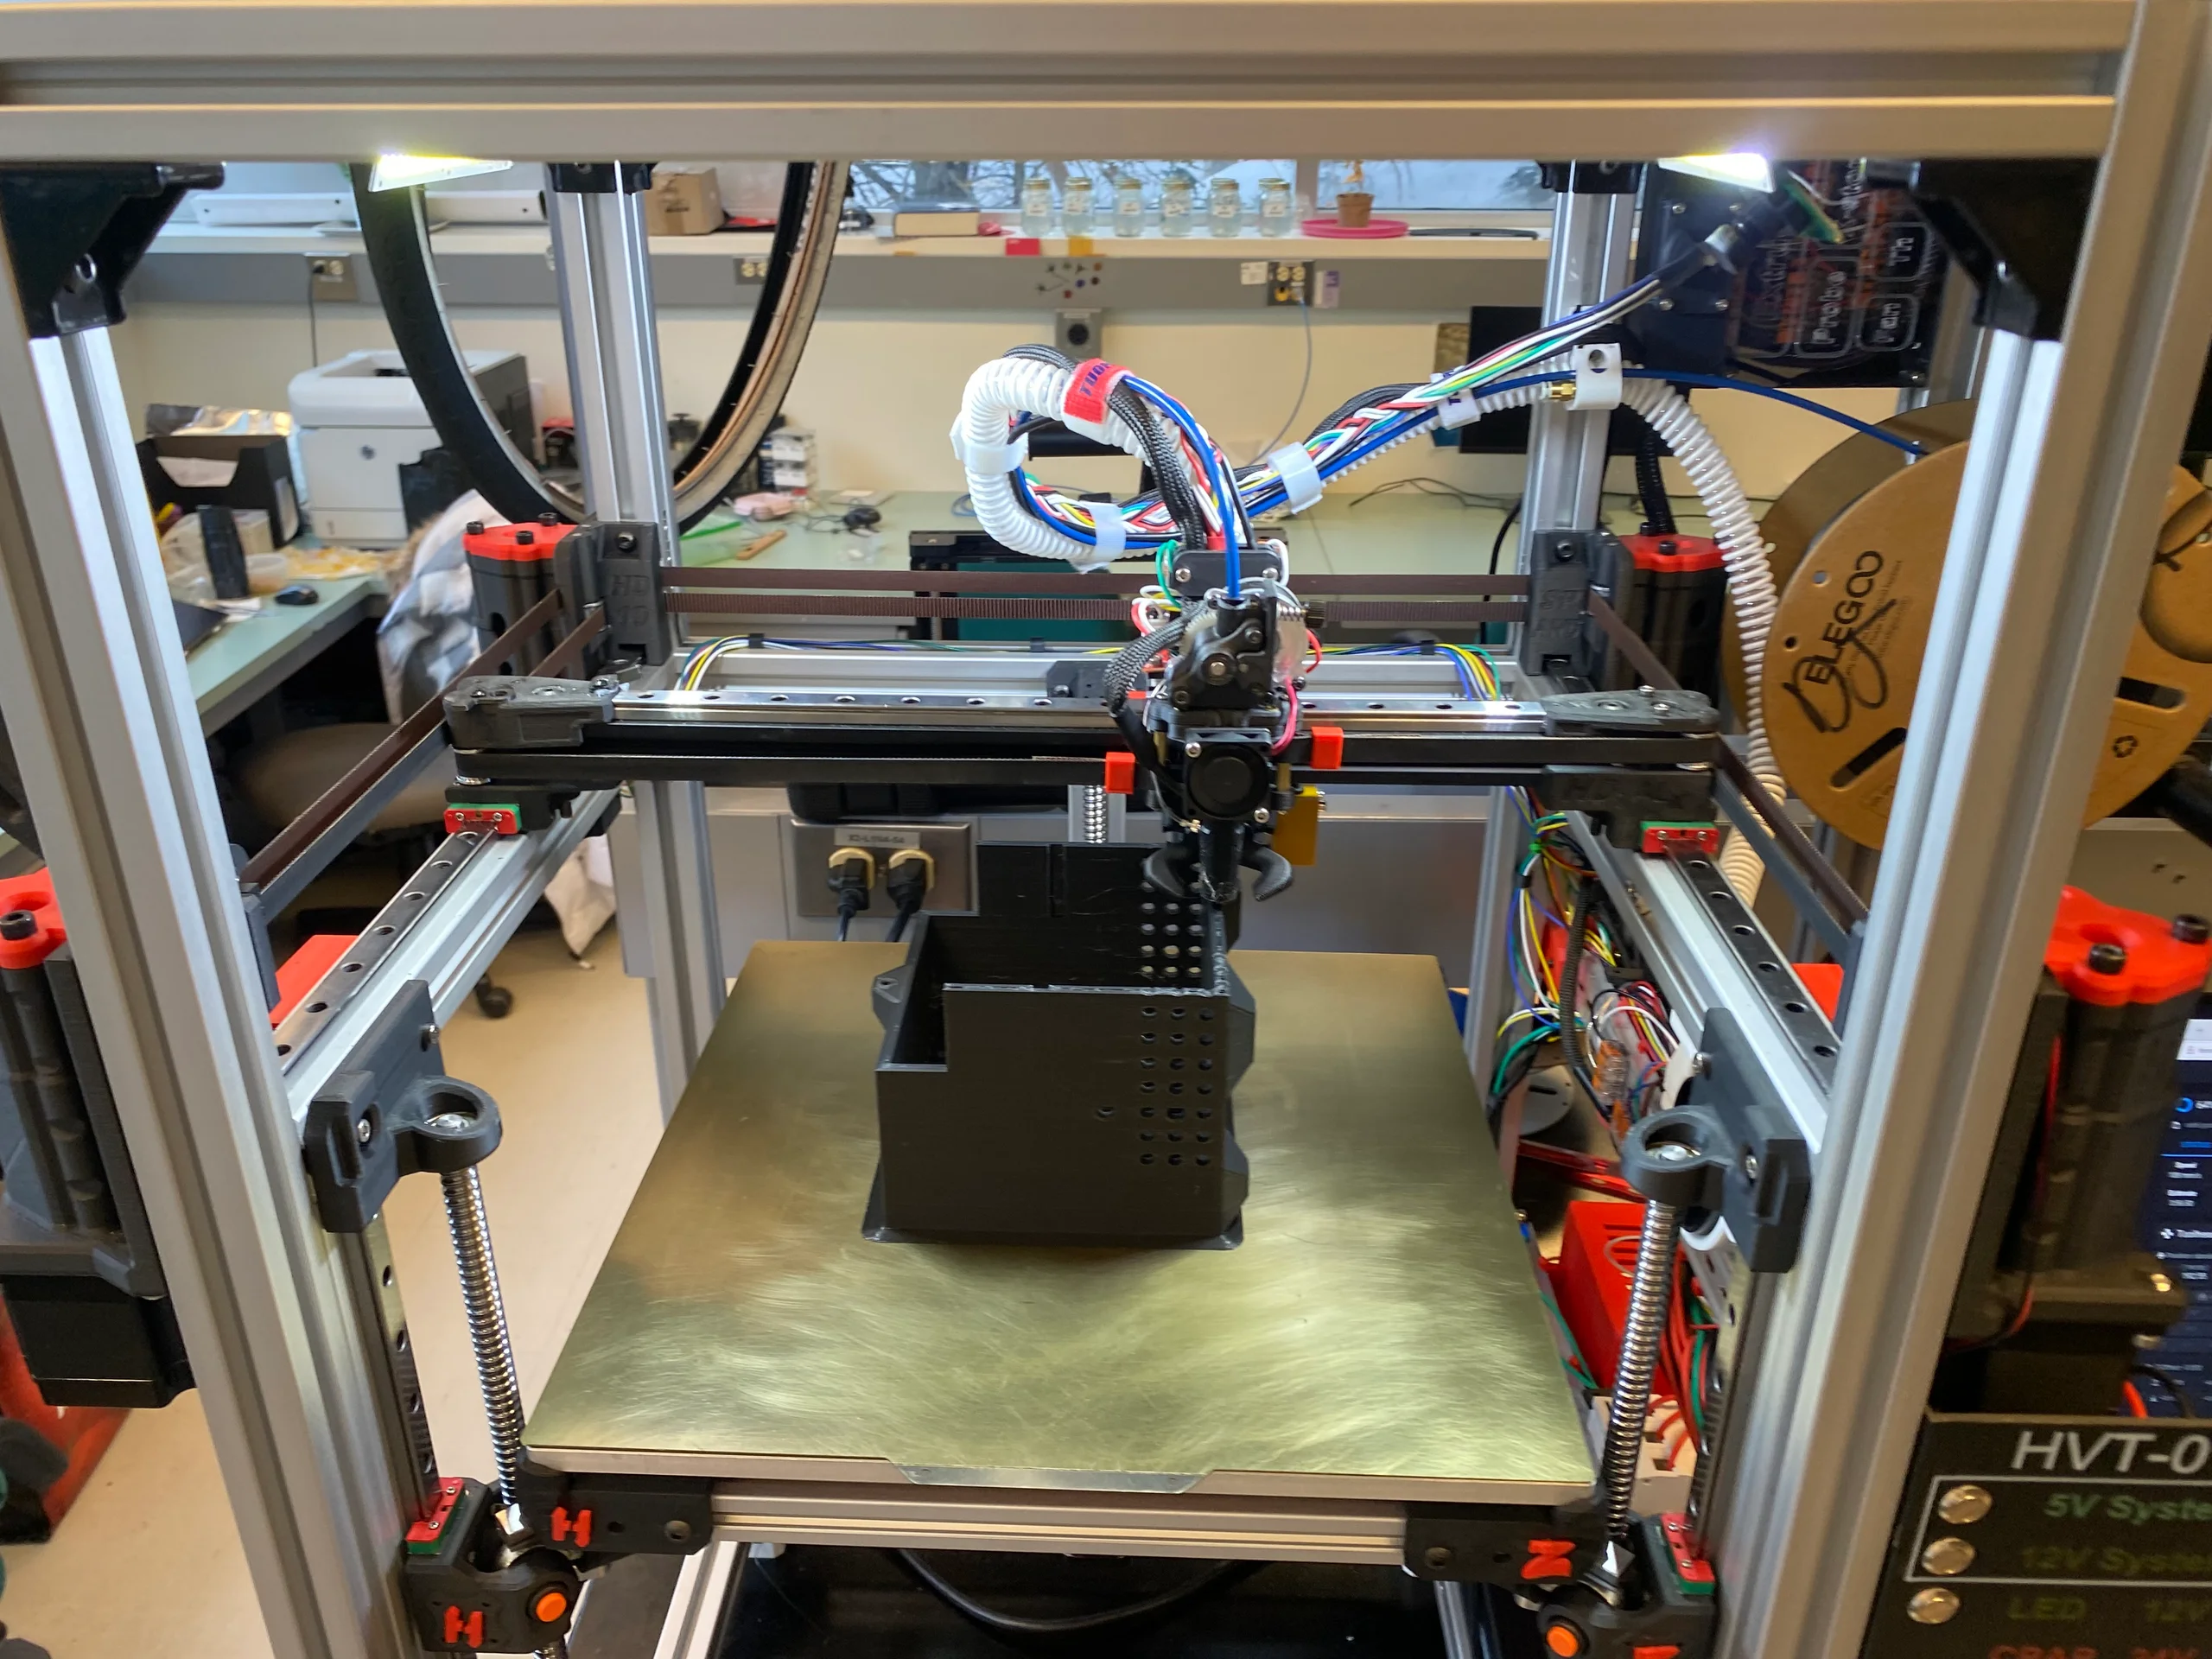
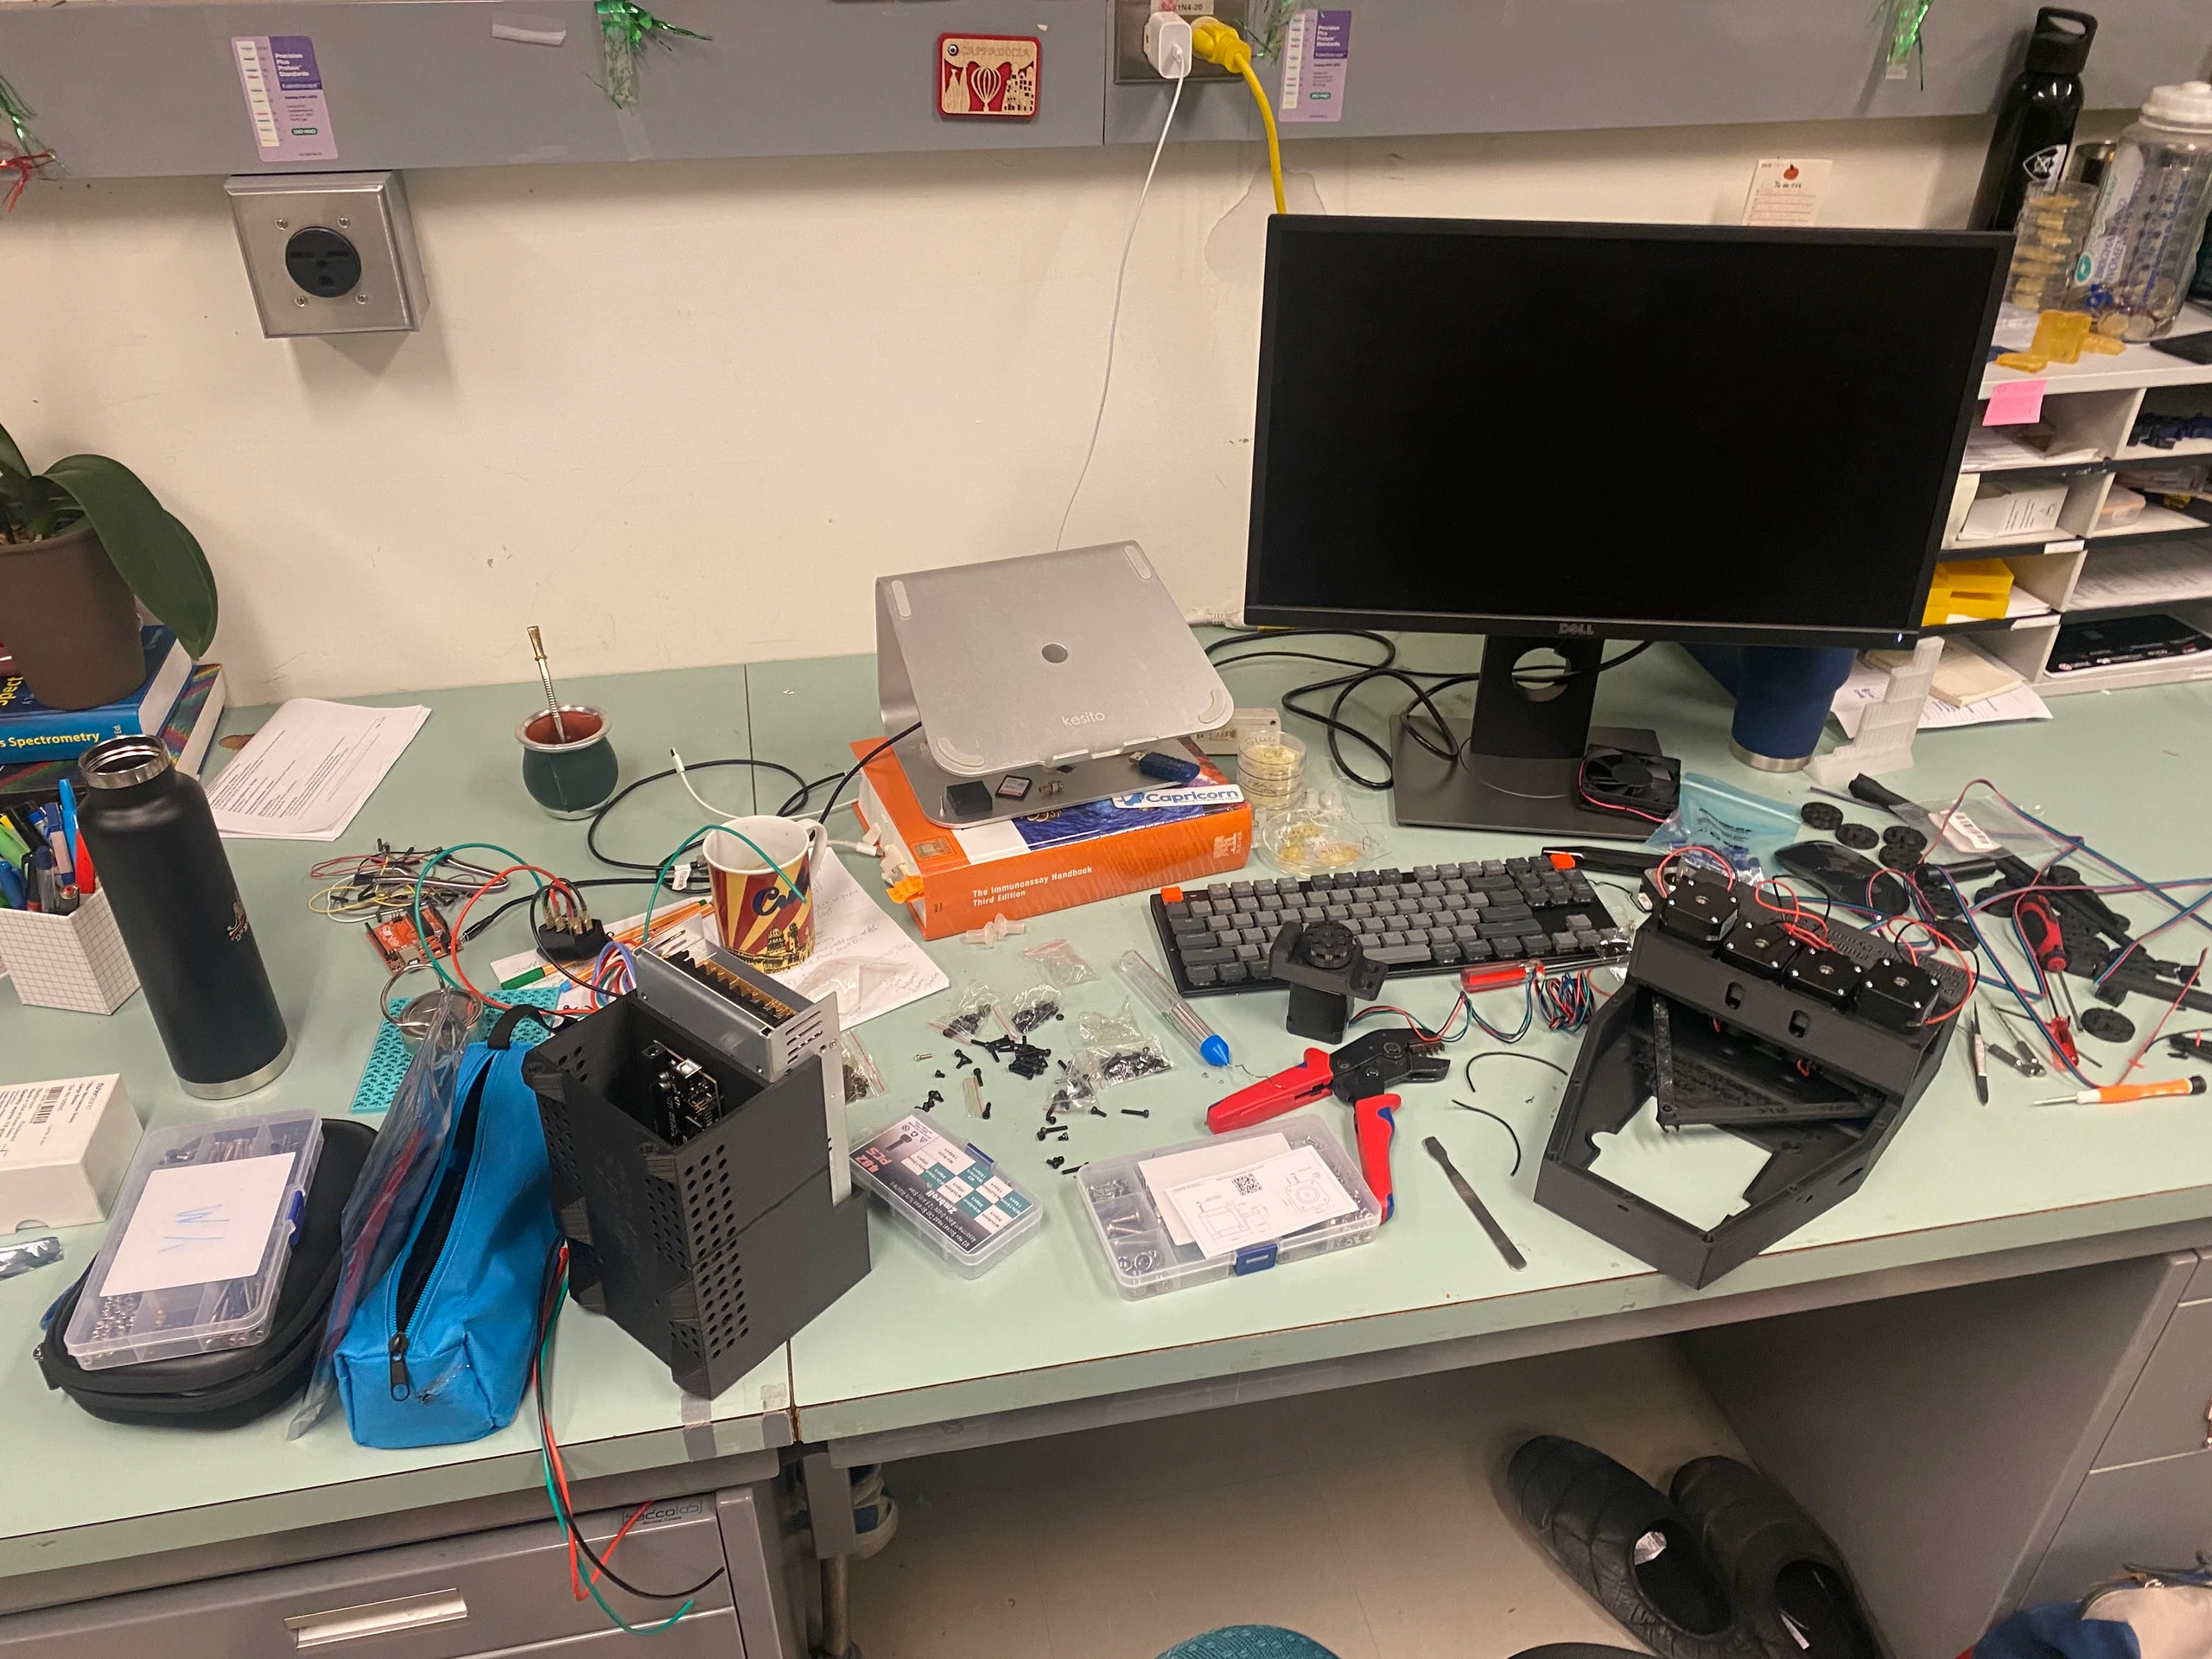
Scroll or swipe to explore. Select a photo to enlarge it, or a play-marked video to watch.
Research & figure sources.
- [1] Dettinger, P. et al. Open-source personal pipetting robots with live-cell incubation and microscopy compatibility.
Nature Communications 13, 2999 (2022). https://doi.org/10.1038/s41467-022-30643-7. Source design; the publication's measured results are not presented as results of this local build.